基于手势交互的机械臂轨迹示教系统
2021-09-06花傲阳
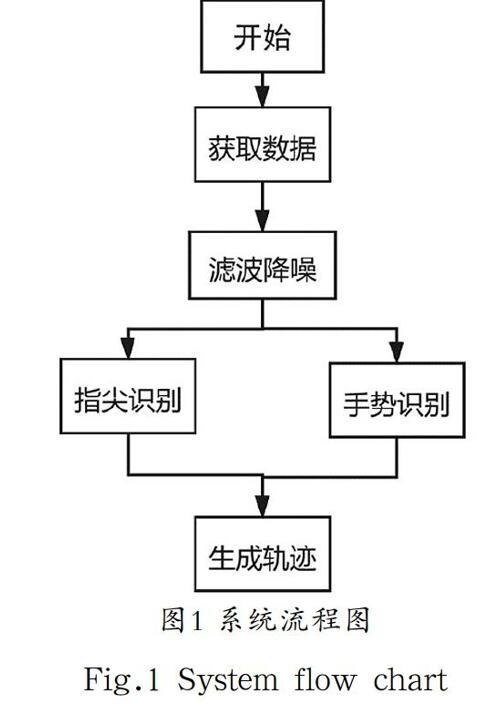
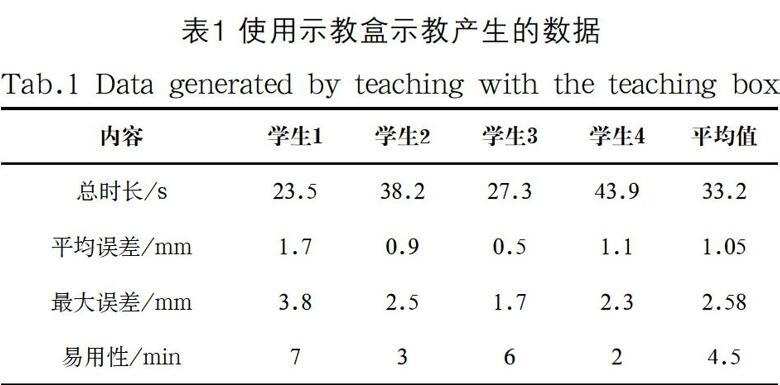
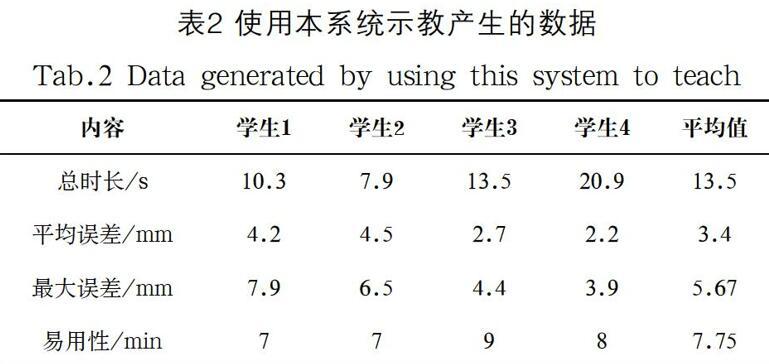
摘 要:为了解决传统机械臂示教方式上手难度高、效率低、人机交互系统不友好的问题,结合机器视觉与神经网络,提出一种基于手势交互的机械臂轨迹示教系统。该系统通过机器视觉定位指尖位置,记录下指尖的运动轨迹并将其用于机械臂的轨迹示教;通过卷积神经网络识别静态手势,用于与机械臂进行如抓取、放置、开始示教等动作的人机交互。系统通过ROS(机器人操作系统)与机械臂通信,驱动机械臂完成示教轨迹的复现。通过设计实验对系统的性能进行评估,结果显示本示教系统具有编程难度低、易用性好、项目部署周期短的优点,可用于复杂轨迹的示教工作,极大地提升了机械臂示教工作的效率。
关键词:机械臂;轨迹示教;机器视觉;神经网络;人机交互
中图分类号:TP391.4 文献标识码:A
Manipulator Trajectory Teaching System based on Gesture Interaction
HUA Aoyang
(College of Mechanical Engineering, University of Shanghai for Science and Technology, Shanghai 200082, China)
huaaoyang@126.com
Abstract: Aiming at the problems of difficulty to learn, low efficiency and unfriendly human-computer interaction system in traditional manipulator teaching methods, this paper proposes to establish a gesture interaction-based manipulator trajectory teaching system combining machine vision and neural network. Fingertip position is located through machine vision, and the movement trajectory of the fingertip is recorded and used for teaching manipulator trajectory. Convolutional neural network is used to identify static gestures, which are used for Human-computer interaction with the manipulator's actions, such as grasping, placing, and teaching. The system communicates with the manipulator through ROS (Robot Operating System), and drives the manipulator to complete the reproduction of the teaching trajectory. The performance of the system is evaluated through experiment designing. Results show that this teaching system has the advantages of low programming difficulty, user-friendliness, and short project deployment cycle. It can be used for teaching complex trajectories, which greatly improves teaching efficiency of the manipulator.
Keywords: manipulator; trajectory teaching; machine vision; neural network; human-computer interaction
1 引言(Introduction)
近年來,我国制造业发展经历了从制造大国向制造强国的转型升级。机械臂是现代工业生产管理过程中的重要组成部分,由于机械臂具有工作精度高、重复能力强、能在恶劣的环境下进行操作等优点,被广泛应用于零部件的焊接、喷涂、装配等工业任务中。目前,机械臂主要包含在线示教及离线示教两种示教方式。在线示教主要通过示教盒进行逐点位示教或直接拖动机械臂示教;离线示教主要是用计算机辅助设计软件制作三维模型,并导入各机械臂厂家的仿真软件中进行轨迹示教[1]。传统示教方法具有操作复杂、人机交互的友好性不高、不同品牌操作方式不同、示教精度依赖于工人熟练度等缺点,因此提出一种简单高效的机械臂示教办法是当前机械臂研究的热点与难点。……