基于SIMULINK的车辆防抱死制动系统控制研究
2016-10-21李振兴周晶晶
李振兴 周晶晶
摘要: 利用Simulink软件建立车辆防抱死制动系统的仿真模型;基于PID控制原理设计以车轮滑移率为控制对象的防抱死制动系统控制器,对防抱死制动控制系统进行仿真。将普通制动系统与防抱死制动系统仿真结果进行对比,结果表明PID控制的防抱死制动系统能有效提高车辆的方向操纵性和制动效能。
Abstract: Firstly, the simulation model of Anti-lock braking system is established by the software of simulink; Secondly, this paper designs a kind of Anti-lock Braking System(ABS) controll system and targeted at the wheel slip ratio based on the PID control strategy, which simulated the system of ABS and analysed the result. The simulation results of the ordinary brake system is contrasted with the Anti-lock braking system, and the results show that PID control ofAnti-lock braking system can effectively improve the direction of the vehicle maneuverability and braking performance.
关键词: 防抱死制动系统;PID;仿真
Key words: anti-lock brake system;PID;simulation
中图分类号:U463.33 文献标识码:A 文章编号:1006-4311(2016)07-0102-03
0 引言
汽车防抱死制动系统是提高车辆行驶安全的重要装置[1]。它能防止车辆在制动时车轮抱死滑移,保障车辆的行驶稳定性和转向操纵性,同时能有效地缩短制动距离,减少交通事故的发生。
防抱死制动系统中最重要的部件是防抱死制动控制器,它决定了防抱死制动系统系统的性能,而控制器的核心是控制算法的选择。目前大部分车辆上采用的是基于经验的逻辑门限控制方法,它的方法简单实用,但调试比较困难,采用经验的方法,不同的车辆需要不同的匹配技术,需要比较多的道路试验加以验证,算法实施复杂而且鲁棒性不强。PID控制算法原理简单,使用方便;适应性强;鲁棒性强。因此,应用PID控制理论,在SIMULINK中仿真研究防抱死制动系统的控制策略及其控制效果。
1 系统模型建立
1.1 单轮车辆模型
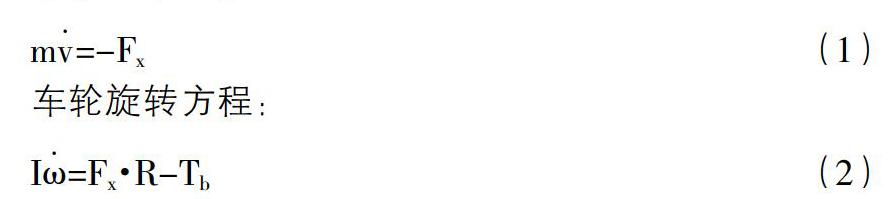
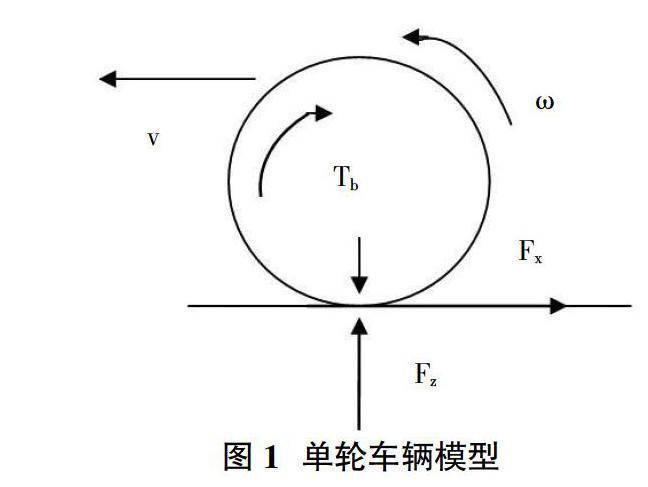
为简化研究问题,采用单轮车辆系统模型如图1所示,忽略空气阻力和车轮滚动阻力;车辆质量均匀分布在每个车轮上,轮胎的机械特性相同;车辆在水平公路上行驶[2]。……
