基于ROS室内巡检机器人的视觉惯性融合定位方法
2021-02-19孙希君王秋滢王水根吴应为
孙希君 王秋滢 王水根 吴应为
摘 要:精确鲁棒的定位系统是保证室内巡检机器人正常工作的重要基础。文章基于机器人操作系统(ROS),针对现有公开视觉算法ORB-SLAM2在低性能计算平台上因计算能力不足导致的特征跟踪丢失问题,提出一种将ORB-SLAM2与惯性导航系统(Inertial Navigation System, INS)解算误差进行卡尔曼滤波融合的方法。经公开数据集验证表明,该方法能够完整地估计出视觉失效时丢失的位姿信息,与ORB-SLAM2相比,定位系统的精度与鲁棒性有效提高。
关键词:ROS;定位;卡尔曼滤波;ORB-SLAM2
中图分类号:TP242 文献标识码:A文章编号:2096-4706(2021)13-0139-06
Visual Inertial Fusion Positioning Method Based on ROS Indoor Inspection Robot
SUN Xijun1, WANG Qiuying2,3, WANG Shuigen4, WU Yingwei1
(1.College of Information and Communication Engineering, Harbin Engineering University, Harbin 150001, China; 2.College of Underwater Acoustic Engineering, Harbin Engineering University, Harbin 150001, China; 3.Key Laboratory of Underwater Acoustic Technology, Harbin Engineering University, Harbin 150001, China; 4.Yantai Iray Technology Co., Ltd., Yantai 264006, China)
Abstract: Accurate and robust positioning system is an important basis to ensure the normal operation of indoor inspection robot. Based on the robot operating system (ROS), aiming at the loss of feature tracking caused by the insufficient computing power of the existing public vision algorithm ORB-SLAM2 on the low-performance computing platform, this paper proposes a method for Kalman filter fusion in the solution errors of ORB-SLAM2 and inertial navigation system (INS). The verification of public data sets shows that this method can completely estimate the pose information lost when visual failure. Compared with ORB-SLAM2, the accuracy and robustness of the positioning system are effectively improved.
Keywords: ROS; positioning; Kalman filter; ORB-SLAM2
0 引 言
在化學工业工厂、电力设备厂房、电力隧道、物流仓储库房等室内高危作业环境下,配备24小时持续巡检机器人可有效提升作业人员的工作效率,并在极大程度上保证员工安全问题。确保巡检机器人正常工作的关键前提是机器人自身可以实现高精度、高可靠性的实时自主定位。
常见的用于单一定位系统的传感器主要有卫星接收机、激光雷达、视觉相机、惯性测量单元(Inertial Measurement Unit, IMU)由于建筑物遮挡等影响室内机器人无法通过卫星信号进行精准定位,激光雷达的价格相对昂贵,而视觉相机与IMU的成本相对低廉、且无须外界提供任何信息便可进行独立自主定位,因此利用视觉相机与IMU进行运载体的定位逐渐引起学术研究者的广泛关注[1]。
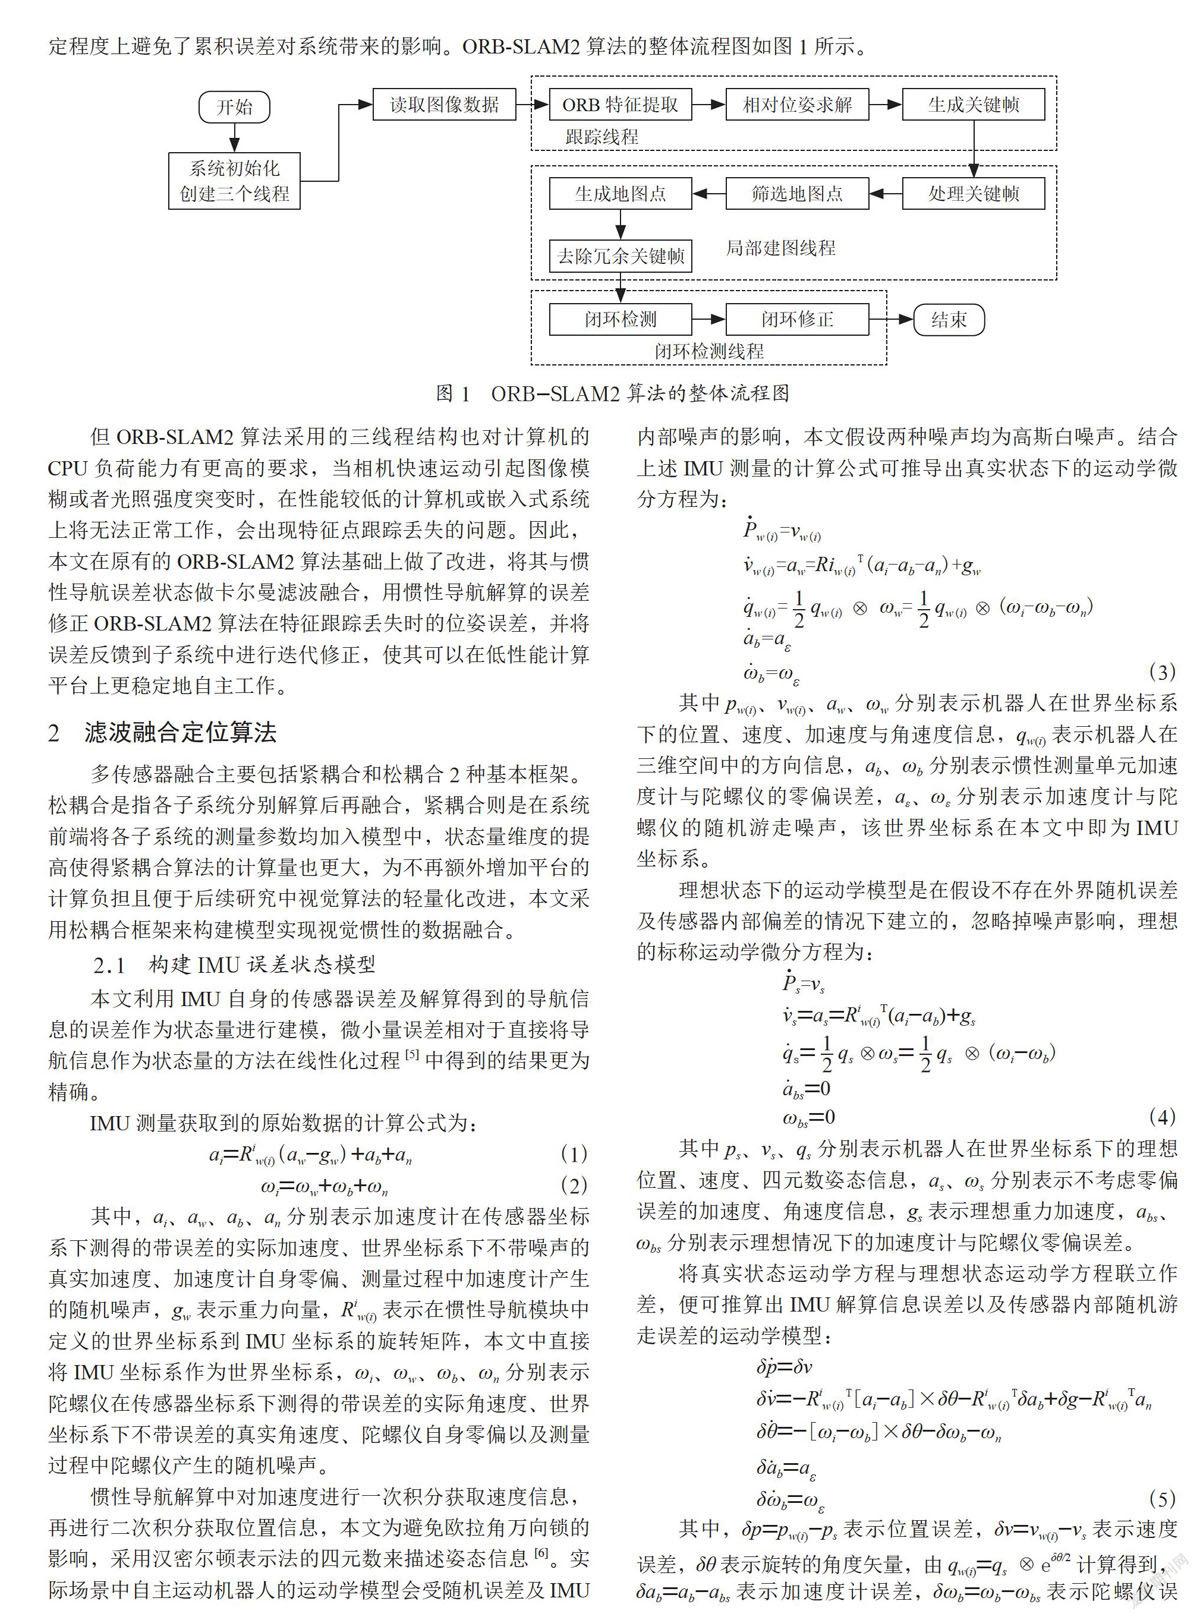
现有的纯视觉算法都存在着易受光照、相机快速运动等问题的影响,基于直接法的DSO(Direct Sparse Odometry)算法[2]在计算速度上相对较快,但是对光……
