BP-PID控制器在双电机消隙伺服系统中的应用
2020-07-04王轩
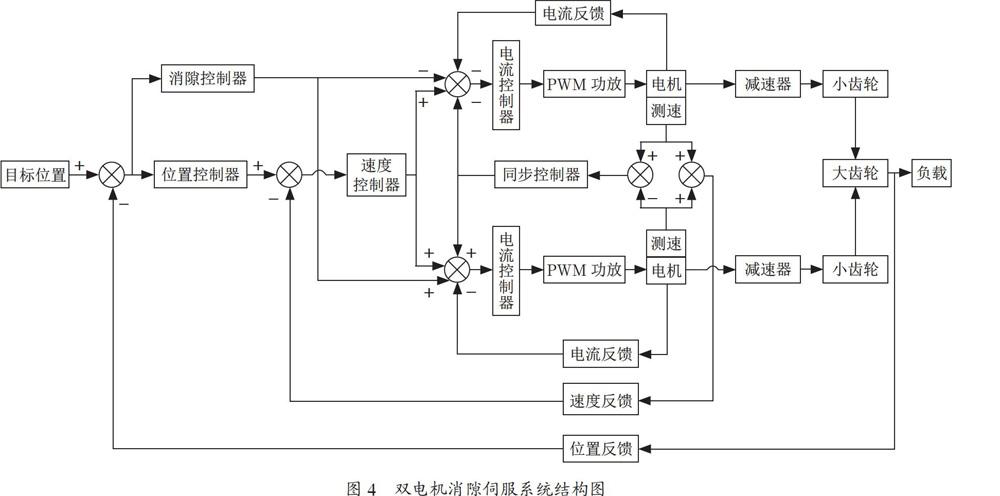
摘 要:为了更好地改进伺服系统性能表现,文章以某双电机消隙伺服系统为背景,首先分析了齿隙对伺服系统性能的影响。然后针对经典PID控制器的局限性,尝试将BP神经网络与经典PID控制器结合在一起,设计了BP-PID控制器。最后通过Matlab/Simulink仿真结果验证了BP-PID控制器使双电机驱动消隙伺服系统的性能表现得到明显改善。
关键词:双电机伺服系统;齿隙;BP神經网络;仿真
中图分类号:TP273 文献标识码:A 文章编号:2096-4706(2020)03-0161-03
Abstract:In order to improve the performance of the servo system,this paper takes a dual-motor anti-backlash servo system as the background.Firstly,the influence of backlash on the servo system is analyzed. Then,aiming at the limitations of the classic PID controller,we tried to combine the BP neural network with the classic PID controller to design the BP-PID controller. Finally,Matlab/Simulink simulation results verify that the performance of the dual-motor anti-backlash servo system is significantly improved by the BP-PID controller.
Keywords:dual-motor servo system;backlash;BP neural network;simulation
0 引 言
伺服系统在实际工况中,齿隙、死区等非线性因素会严重影响伺服系统的性能表现,其中齿隙对伺服系统性能影响最大[1],易引起系统振荡,产生较大的稳态误差。因此双电机驱动方式通常被采用于伺服系统设计中,能够保证伺服系统有效地抑制齿隙对性能的影响[2]。
经典PID控制器有着算法结构简单、适用面广等特点,但经典PID控制器想要取得良好的控制效果,就必须调整好比例、积分和微分三种控制作用之间的关系,而双电机伺服系统作为复杂的非线性系统,经典PID控制器很难达到最优的控制效果。神经网络因具有逼近任意非线性函数的能力,使得我们可以将神经网络与经典PID控制器结合在一起,通过BP神经网络系统来完成控制器最佳控制参数调整的功能,从而实现一种由BP神经网络参数自整定的PID控制。
1 双电机消隙伺服系统
1.1 齿隙对伺服系统性能影响
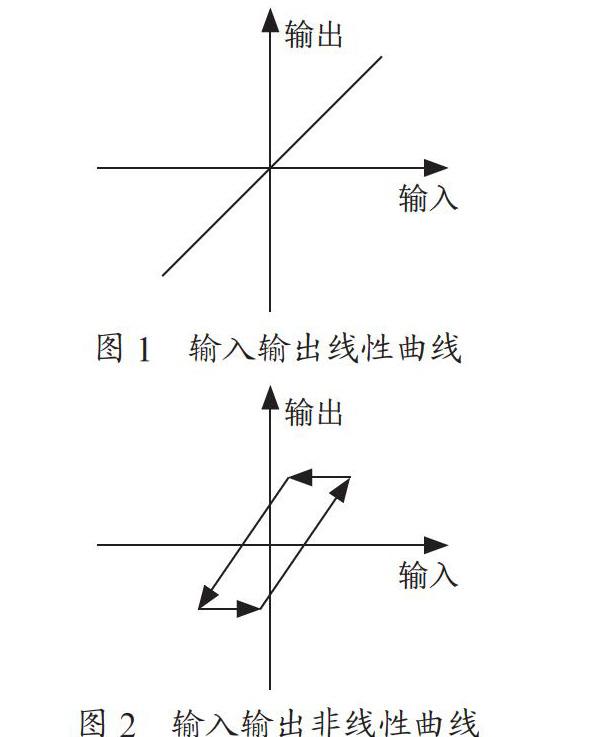
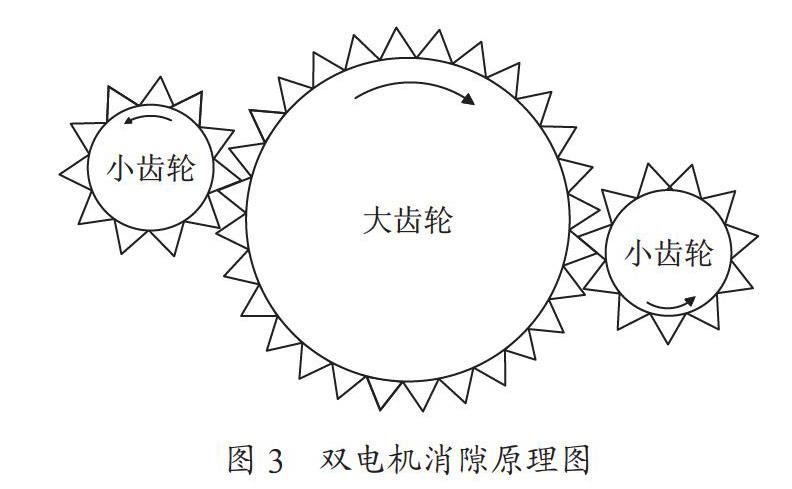
理想工况下,齿轮传动的输入输出关系应当是如图1所示的线性关系。但在现实工况中,齿隙必然存在于一对相互啮合的齿轮之间。……
