基于改进ORB算法的VSLAM特征匹配算法研究
2020-05-21杨立闯马杰马鹏飞王旭娇王楠楠
杨立闯 马杰 马鹏飞 王旭娇 王楠楠
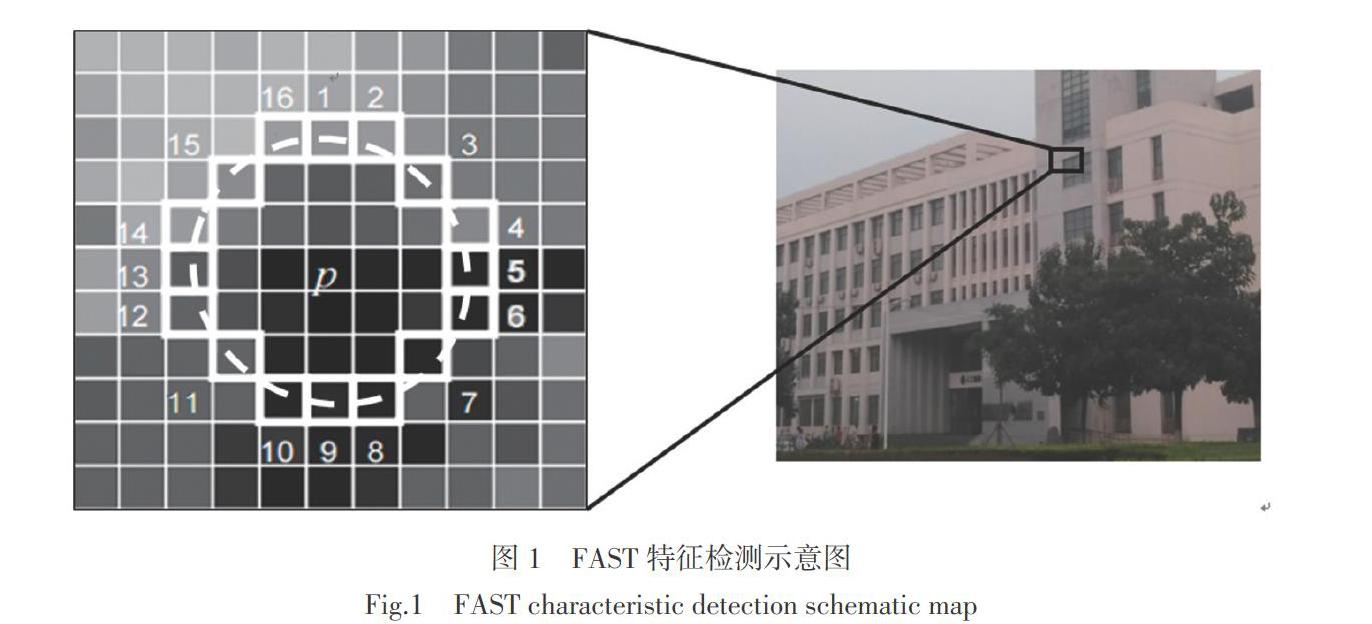
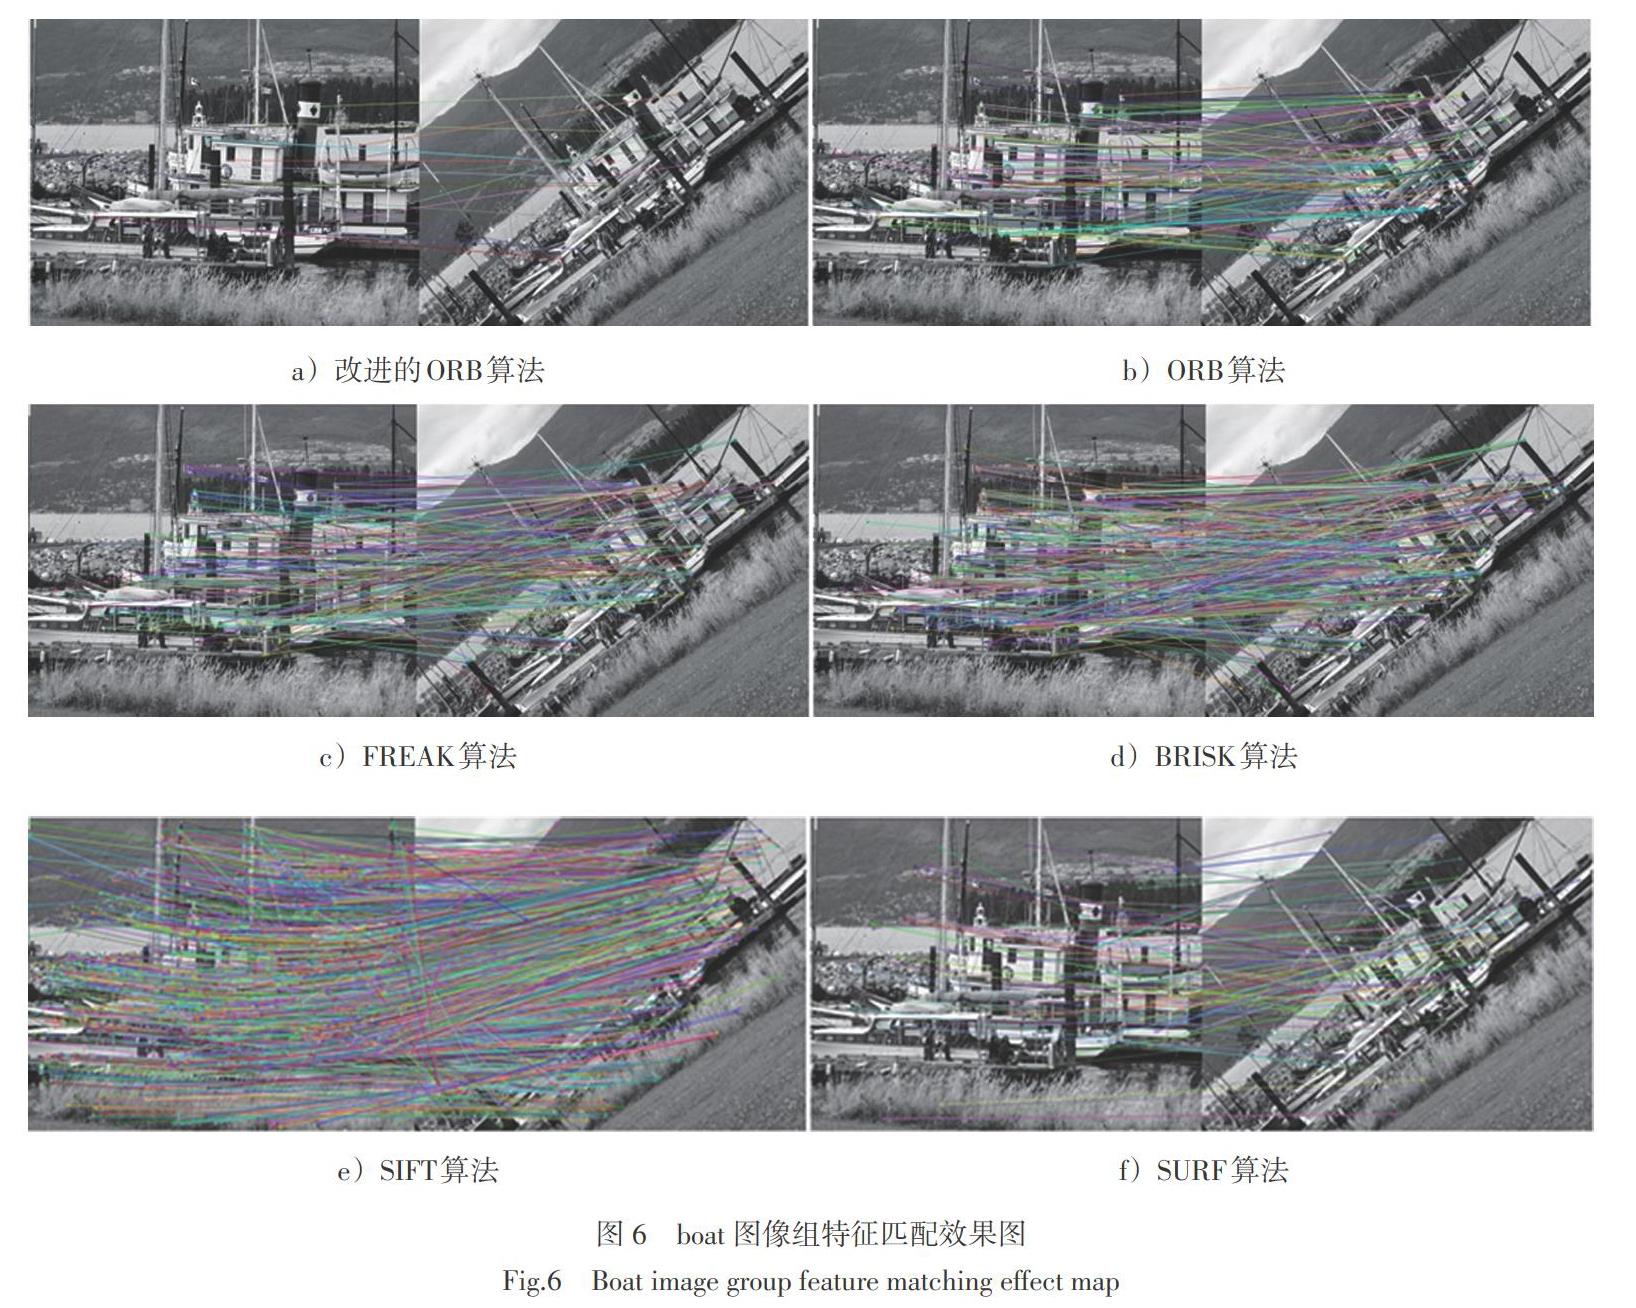
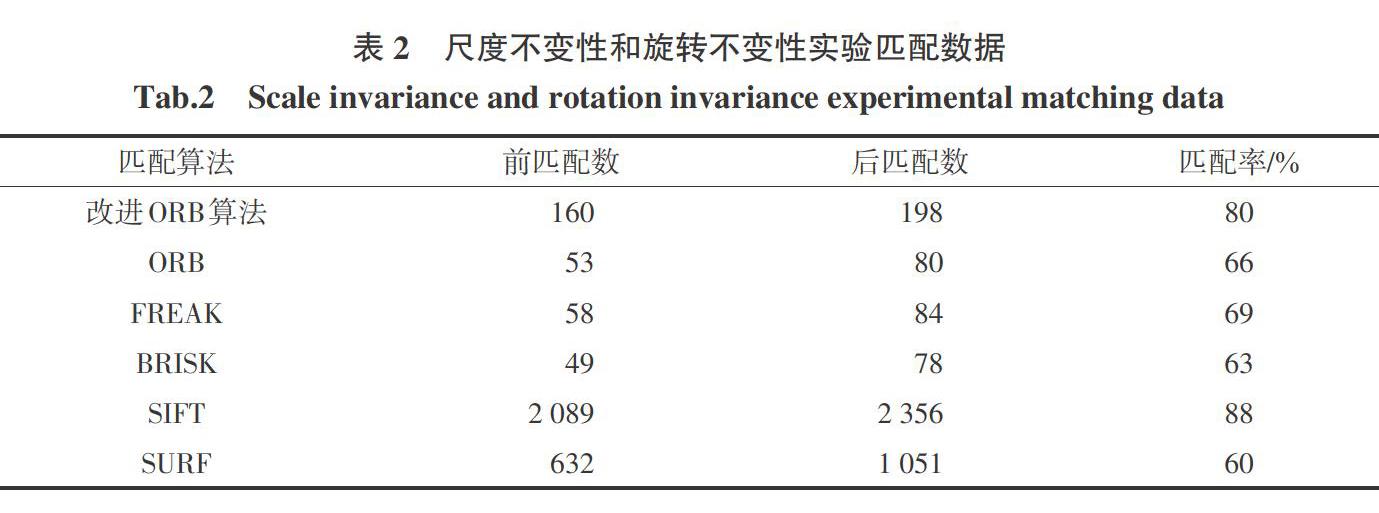
摘要 针对传统特征匹配算法耗时较长、匹配率不高的问题,提出一种改进ORB的图像特征匹配算法。首先对FAST特征检测算法进行改进,构建非线性尺度空间,采用非线性扩散滤波方法,对金字塔进行构建,通过快速显示扩散形式(FED)进行求解,得到尺度空间上的图像,并采用灰度质心法方法,对特征的角点方向进行计算。然后对FREAK算法采样模式进行优化,采用改进的描述子构建特征向量。最后采用GMS匹配算法剔除伪匹配点对,有效降低误匹配概率。实验证明,相比SIFT、SURF、FREAK、BRISK和ORB算法,本文改进的算法在耗时和匹配率方面均有明显效果,并在旋转、尺度、光照等变换条件下,具有较强的鲁棒性,适用于VSLAM系统。
关 键 词 特征匹配;改进ORB;FAST;特征检测;VSLAM
中图分类号 TP391.41 文献标志码 A
Research on VSLAM feature matching algorithm based on improved ORB algorithm
YANG Lichuang, MA Jie, MA Pengfei, WANG Xujiao, WANG Nannan
(School of Electronics and Information Engineering, Hebei University of Technology, Tianjin 300401,China)
Abstract Aiming at the problem of long time consuming and low matching rate of traditional feature matching algorithm, an improved image feature matching algorithm based on ORB is proposed. Firstly, the FAST feature detection algorithm is improved to build a nonlinear scale space, and the pyramid is constructed by using the nonlinear diffusion filtering method. The image in the scale space is obtained by solving the FAST display diffusion form (FED), and the corner direction of the feature is calculated by using the grayscale centroid method. Then, the sampling mode of the FREAK algorithm is optimized and the improved descriptor is used to construct the feature vector. Finally, the GMS matching algorithm is used to eliminate the false matching point pairs and effectively reduce the false matching probability. Compared with SIFT, SURF,FREAK,BRISK and ORB algorithms, the improved algorithm in this paper has obvious effects in terms of time consumption and matching rate, and has strong robustness under rotation, scale and illumination conditions, which is suitable for VSLAM systems.
Key words feature matching; improved ORB; FAST; feature detection; VSLAM
0 引言
同時定位与地图构建(Simultaneous Localization and Mapping,SLAM)通过搭载某种设定的传感器,在没有环境先验信息的情况下,在运动过程中构建环境的模型,同时估计自己的运动[1]。若此传感器为视觉相机,则称为视觉SLAM,简称VSLAM。经典视觉SLAM框架主要包括视觉里程计(VO)、后端优化、回环检测以及地图构建等部分。精确的图像匹配是系统良好运动估计以及建图过程的前提,因此对特征匹配算法的研究至关重要。局部特征图像特征匹配方法对旋转、尺度变换、光照以及高斯噪声等具有较好的不变性,在智能识别领域,图像已经成为信息获取的重要途径,因而匹配算法在目标追踪[2]、医疗疾病检测[3]、安防监控[4]、工业产品检测[5]、空间遥感技术[6]等重要领域的研究及应用越来越广泛。……