基于卡尔曼滤波算法的ADS-B航迹预测
2021-11-03卢献宇张媛媛
卢献宇 张媛媛
DOI:10.19850/j.cnki.2096-4706.2021.08.014
摘 要:廣播式自动相关监视(Automatic Dependent Surveillance-Broadcast,ADS-B)系统作为民航独立的监视手段具有一定的脆弱性。现提出基于卡尔曼滤波算法进行ADS-B航迹预测的方案,为进一步鉴别ADS-B位置信息的真伪提供可靠的技术支撑。通过解析ADS-B报文中的位置信息,建立卡尔曼滤波模型,计算航迹预测观测点数,完成基本的航迹预测实验。理论分析和仿真实验结果表明基于卡尔曼滤波算法的ADS-B航迹预测效果很好。
关键词:ADS-B;航迹预测;卡尔曼滤波;蒙特卡洛方法
中图分类号:TP391.9 文献标识码:A 文章编号:2096-4706(2021)08-0048-04
ADS-B Track Prediction Based on Kalman Filtering Algorithm
LU Xianyu1,ZHANG Yuanyuan2
(1.Guangzhou Civil Aviation College,Guangzhou 510403,China;
2.CAAC Xinjiang Air Traffic Administration,Urumqi 830015,China)
Abstract:Automatic Dependent Surveillance-Broadcast(ADS-B)system has a certain vulnerability as an independent surveillance means of civil aviation. In this paper,a scheme of ADS-B track prediction based on the Kalman filtering algorithm is proposed,which provides reliable technical support for further identifying the authenticity of ADS-B position information. Through analyzing the position information in the ADS-B message,the Kalman filtering model is established,the observation points of track prediction are calculated,and the basic track prediction experiments are completed. Theoretical analysis and simulation experiment results show that the ADS-B track prediction based on Kalman filtering algorithm has good effect.
Keywords:ADS-B;track prediction;Kalman filtering;Monte Carlo method
0 引 言
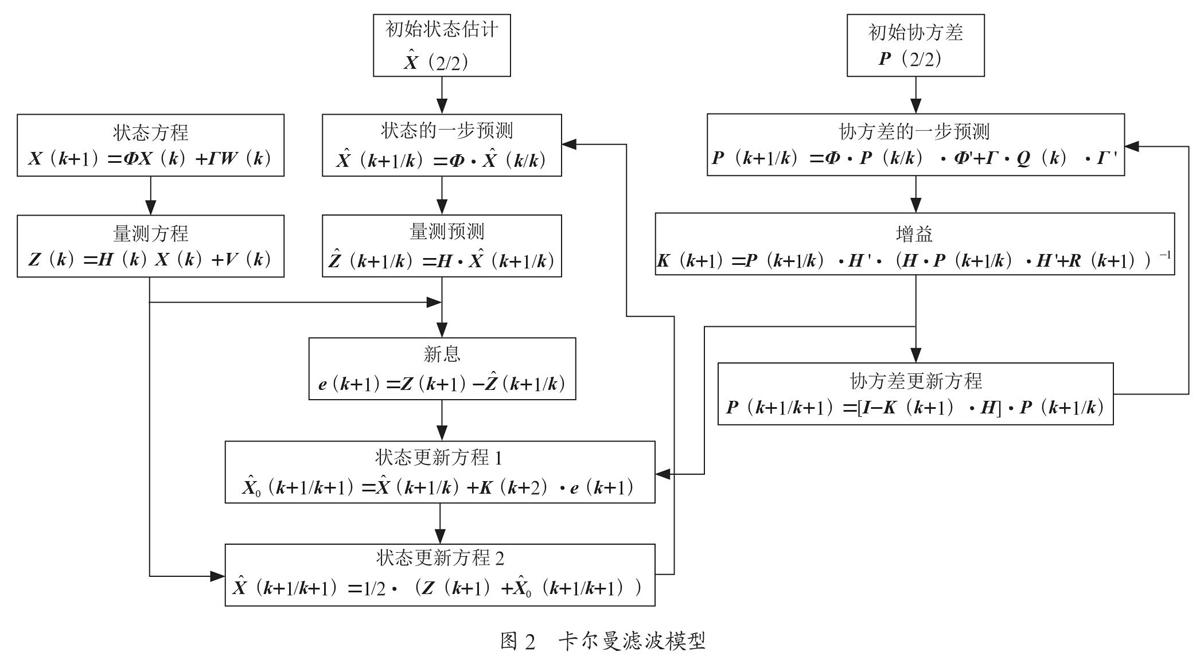
卡尔曼滤波算法是一种最小化均方误差的线性滤波方法,它在观测方程和目标状态转移方程的基础上,使用迭代的方式对目标的状态进行预测和更新。正是它的递推型结构,有利于实现数据的实时处理,因此,作为一种最优估计理论广泛应用于航迹滤波中。
飞行器机载ADS-B系统通过1090ES数据链广播其位置、速度等信号,该信号由地面站天线接收后可生成CAT021格式的报文信息,提供给空管部门等用户。由于ADS-B报文是一种开放的数据格式(CAT021格式),其各项数据均通过无线链路以非加密方式进行广播,任何用户均可从报文中获取该目标位置信息,研究人员亦可获取目标位置信息[1],因此,ADS-B报文信息易受黑客侵入而产生虚假信息,面临着安全性挑战。
针对此问题,可从卡尔曼滤波跟踪目标轨迹的角度切入,讨论并对使用卡尔曼滤波算法进行的ADS-B航迹预测进行仿真分析,为下一步辨别ADS-B信息的真伪提供可靠的理论和实验依据。……