基于模糊推理的复杂地形下六足机器人步态辅助决策方法
2020-05-21尤波王明磊许家忠李佳钰丁亮高海波
尤波 王明磊 许家忠 李佳钰 丁亮 高海波

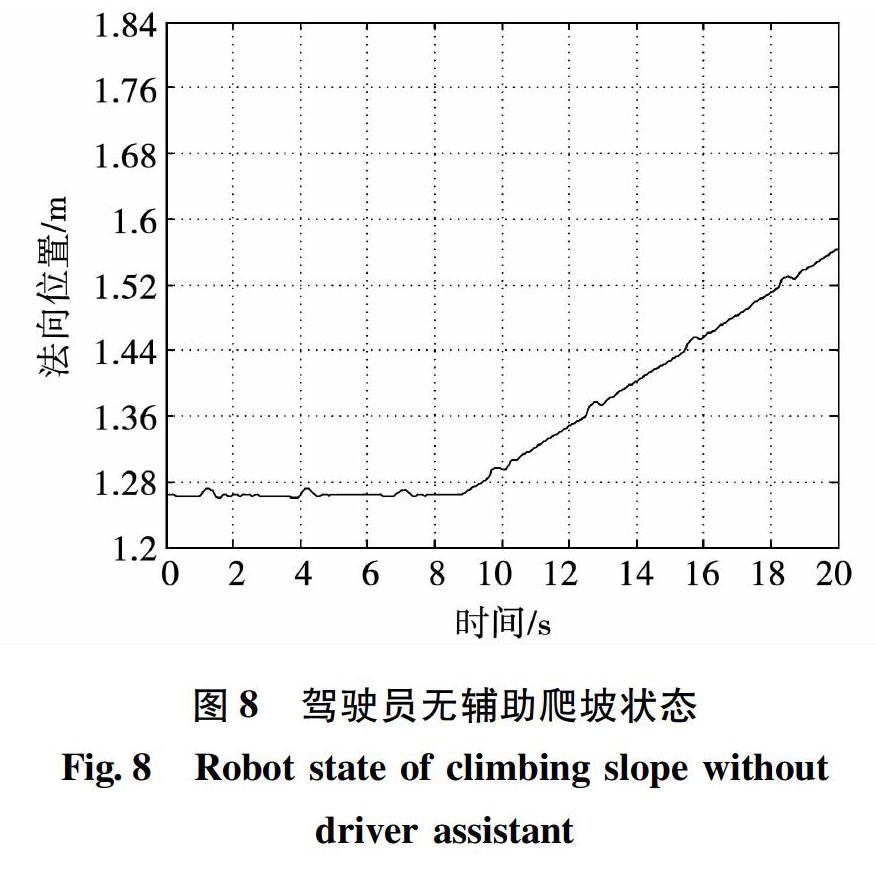
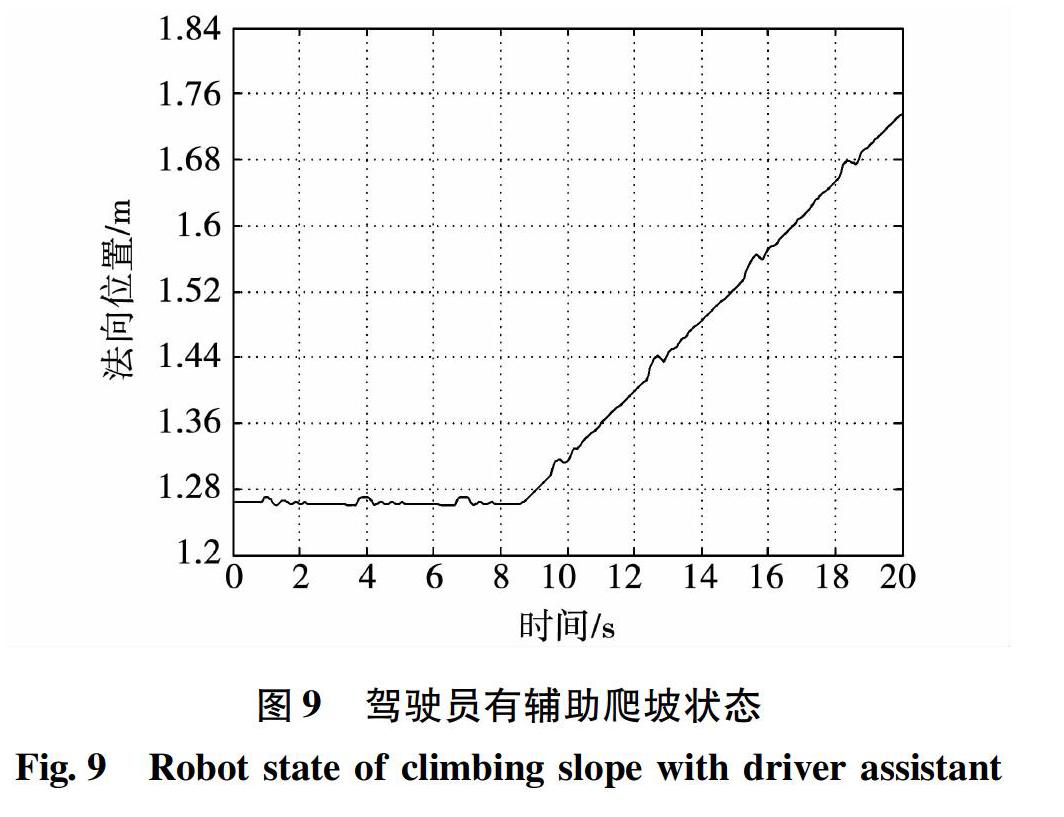
摘 要:目前载人六足机器人驾驶员在复杂地形下步态决策完全依赖主观经验,为提高驾驶员决策质量,提出一种步态辅助决策方法。建立驾驶员信息处理模型,将地形环境作为决策因素,步态及优先级作为决策结果,利用模糊推理系统进行辅助决策;将坡度、起伏度、粗糙度及障碍高度明确为地形特征量,划分其隶属度并制定模糊规则库;利用半物理仿真操纵平台对比驾驶员在无辅助和有辅助时的决策结果。实验结果表明,辅助决策方法能够辅助驾驶员在地形变化时做出合理决策,提高六足机器人在复杂地形下的稳定性与操纵性。
关键词:六足机器人;辅助决策;驾驶员模型;地形评估;模糊推理
DOI:10.15938/j.jhust.2020.01.015
中图分类号: TP242
文献标志码: A
文章编号: 1007-2683(2020)01-0100-08
Abstract:The drivers of manned hexapod robots rely on subjective experience in decision-making in complex terrainIn order to improve the quality of drivers′ decision-making, an auxiliary decision-making method is proposedThe information processing model of drivers is established, and the terrain is used as the decision factor while the priorities of gaits as the resultThe fuzzy decision-making system is established to assist the driversThe slope, fluctuation, roughness and barrier height are defined as the terrain features, degrees of membership are classified and the fuzzy rules are formulatedThe semi-physical simulation platform of the hexapod manipulation is used to compare the decision results of the drivers with auxiliary and without auxiliaryThe experimental results show that the auxiliary decision method can assist the driver to make reasonable decisions when the terrain changes, and increase stability and maneuverability of the hexapod robot in complex terrain-
Keywords:hexapod robots; assistant decision-making; driver model; terrain assessment; fuzzy reasoning
0 引 言
足式机器人是近代仿生设计的典型应用,运动方式上具有非连续支撑的特点,因此对地形的鲁棒性好,可适应更多的地形。六足机器人在运动过程中由于支撑足数量较多可以保持良好的稳定性,同时在运动控制方面也具有较多的研究成果[1-2]。因此六足机器人在工程应用领域受到更多的重视。
目前,在六足机器人操纵系统的决策方面已经取得了许多成果,主要体现在自主步态生成与足端轨迹规划方面。赵小川等[3]基于Webots仿真软件对六足机器人步态进行规划;Aparna等[4]生成六足机器人的三种规则波动步态,通过遥操作控制机器人完成任务;Belter等[5]通过机器人仿真模型对步态进行迭代优化,实现六足机器人在平坦地形上的快速运动。……