基于非线性PID的列车速度控制
2021-11-03陈旭杨振波
陈旭 杨振波
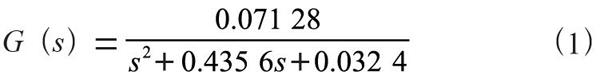
DOI:10.19850/j.cnki.2096-4706.2021.08.011
摘 要:列车自动驾驶系统能提高轨道交通的效率,而它的主要功能是对列车速度的自动控制。与其他的一些控制对象不同,列车速度的自动控制除了要控制好速度以外,还需要考虑到乘客的舒适感。为此,文章设计了一种基于非线性PID原理的控制器,并通过MATLAB软件的Simulink模块进行了仿真。仿真结果表明,该控制器能在保证乘客舒适性的情况下有效跟踪目标速度信号。
关键词:PID控制;非线性PID控制;列车自动驾驶系统
中图分类号:TP273 文獻标识码:A 文章编号:2096-4706(2021)08-0038-04
Train Speed Control Based on Nonlinear PID
CHEN Xu,YANG Zhenbo
(The College of Information Engineering,Guangzhou Vocational and Technical University of Science and Technology, Guangzhou 510550,China)
Abstract:Automatic train operation can improve the efficiency of rail transit,and its main function is automatic control of train speed. Different from some other control objects,the automatic control of train speed not only needs to control the speed,but also needs to take the comfort of passengers into account. Therefore,a controller based on nonlinear PID principle is designed in this paper,and the simulation is carried out through Simulink module of MATLAB software. The simulation results show that the controller can effectively track the target speed signal under the condition of ensuring the comfort of passengers.
Keywords:PID control;nonlinear PID control;automatic train operation
0 引 言
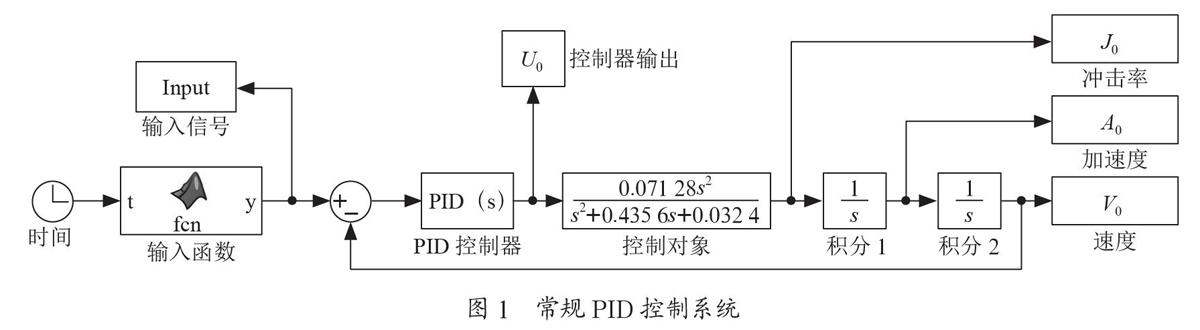
作为列车自动驾驶系统中最主要的功能,对速度控制的效果关系到列车系统运行性能的好坏。一个好的列车速度控制策略除了要达成速度控制本身的快速性、精确性、以及稳定性以外,还需要顾及到列车上的乘客的舒适性。为满足上述指标,常见的做法是先根据速度和对舒适性的要求生成一条平滑的目标曲线,再令控制系统以正常的方式去跟踪速度的目标曲线[1]。这种方式的控制策略对控制器的要求主要体现在控制超调量上,因为对舒适性的考虑基本由对速度的目标曲线的规划去解决。而与之不同的是,不依赖于对目标速度曲线的规划,本文所设计的控制器即使是在阶跃信号输入的情况下也能满足控制系统对消除速度误差以及保证舒适性的要求。
1 控制对象分析
用于评价列车速度控制的效果的指标有很多,如,速度控制与位置控制的“快”“准”“稳”,又如能耗还有舒适性等[1]。……