机器人焊接激光传感器装夹及调节工具设计
2021-09-13贾瑞燕
贾瑞燕
摘要: 针对机器人焊接座环时的焊缝激光跟踪,设计了激光传感器装夹及调节工具,主要由抱箍、橡胶衬垫、第一固定螺栓、第一套环、连杆、顶丝、伸缩螺杆、第二套环、第二固定螺栓、连接板等部分组成,通过旋转连杆、伸长或缩短伸缩螺杆、旋转连接板,对激光传感器进行多自由度调节,使激光以适合角度和位置扫描焊接坡口,成功获取跟踪特征点,实现激光传感器的有效调节和焊缝跟踪。
关键词: 激光传感器; 装夹工具; 自由度调节; 工具设计
中图分类号: TG 439.4
Design of clamping and adjusting tool of the laser sensor of a robot welding system
Jia Ruiyan
(Harbin Electrical Machinery Company Limited, Harbin 150040,Heilongjiang, China)
Abstract: The clamping and adjusting tool of the laser sensor was designed for arobot welding tracking of stay ring. The tool included hoop, a rubber gasket,a first fixing bolt, a first set ring, aconnecting rod, a jacking screw, a telescopic screw, a second set ring, asecond fixing bolt and a connecting plate. The laser could be used to scan the welding groove with suitable angle and position by adjusting the connecting rod, telescopic screw and connecting plate. With the change of multiple degrees of freedom, the tracking feature points could be successfully obtained, which proved the feasibility of the adjustment of the laser sensor and weld tracking system.
Key words: laser sensor;clamping; adjusting of the degrees of freedom; tool design
0 前言
抽水蓄能座環是一种大型焊接结构件,主要由环板、固定导叶、蜗壳拼装焊接而成。环板和固定导叶厚度大,且均为高强钢,预热温度需100 ℃以上,焊工不但劳动强度高,且狭小高温的工作环境恶劣,采用机器人替代焊工作业是制造业发展趋势[1]。抽水蓄能座环环板与固定导叶之间的K形焊缝,适合采用机器人进行焊接[2],由于该焊缝为多层多道焊,采用在焊枪前端安装激光传感器进行寻位和跟踪[3],以实现智能调节,保证焊接质量[4]。
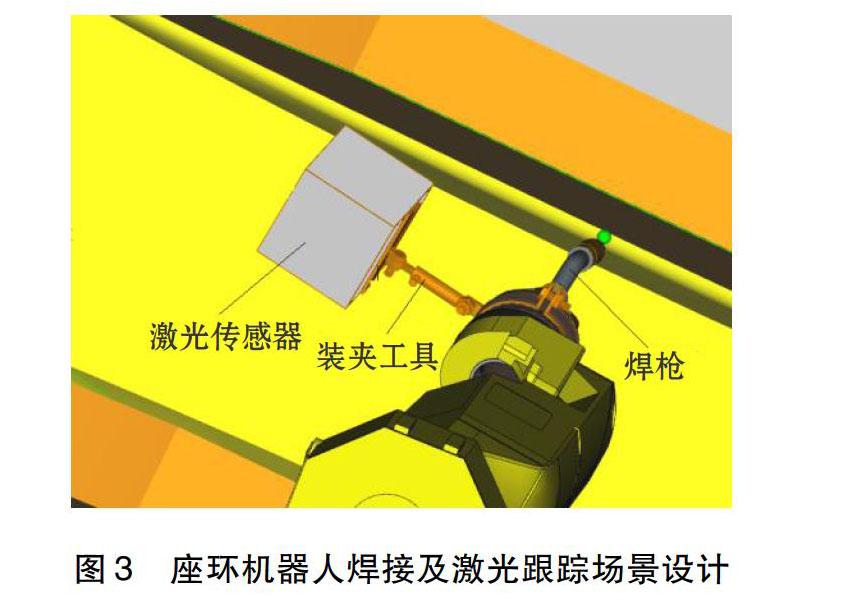
焊接过程中,不同位置焊缝焊枪角度和焊接方向需进行调整,激光传感器与焊枪的相对位置也需相应调节[5],以成功实现对焊接坡口的激光扫描,常规激光传感器的装夹工具仅能固定一个工作位置,无法满足多位置、多角度、多方向的调节。鉴于此,设计了一种焊接机器人激光传感器装夹及调节工具。
1 焊接场景
1.1 坡口形式及焊接要求
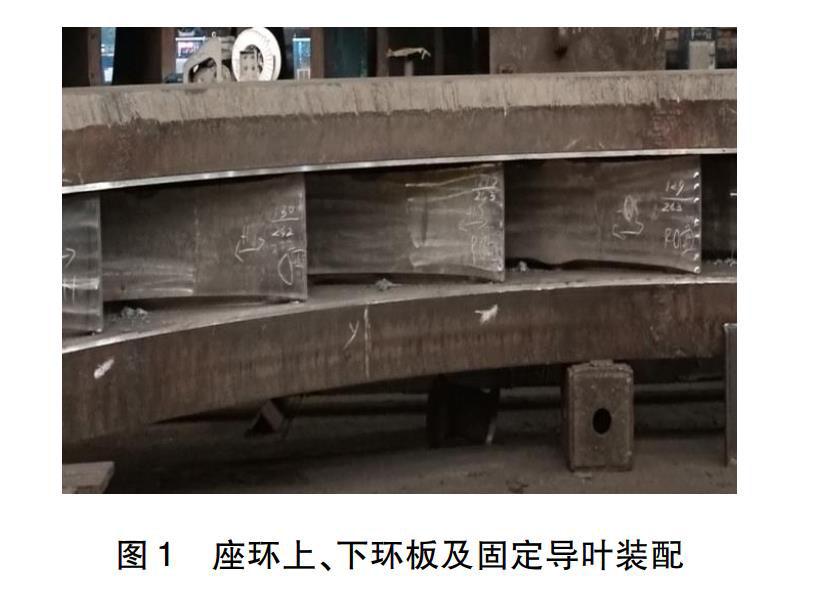
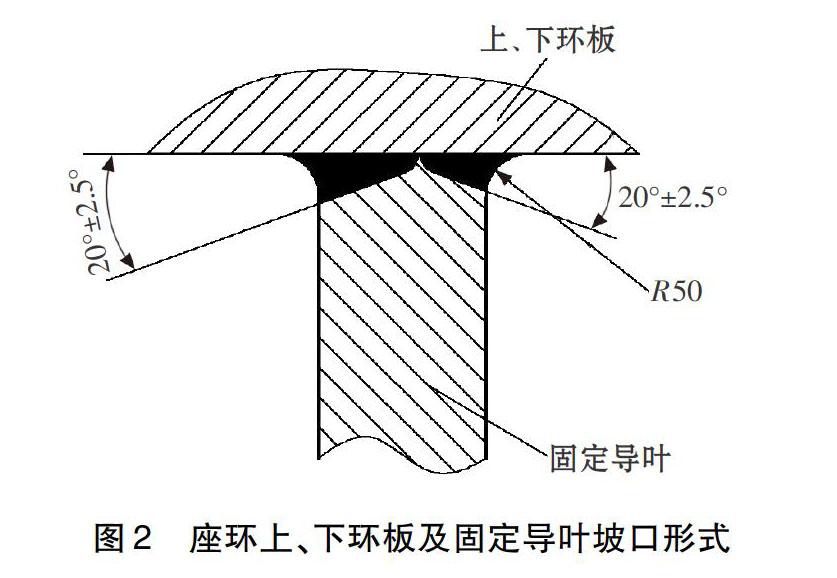
座环采用机器人焊接的位置为上、下环板与固定导叶之间的焊缝,如图1所示。……