一种仓储AGV路径规划最优策略方法的实现
2021-08-03王海霞
王海霞
摘要:路径规划是自动导引车系统( AGVS)路径管理系统的关键技术,主要用来规划智能仓储中单台或多台自动导引车( AGV)的作业路径。研究并检验了一种基于迪杰斯特拉算法的堆优化路径规划策略方法,通过仓库多台AGV路径规划案例,表明可以实现最优的单车及多车路径规划策略,缩短了车辆在仓库中的作业时间,提高了AGV的使用效率。
关键词:自动导引车系统路径管理系统;迪杰斯特拉算法;优化策略
中图分类号:TP23 文献标志码:A 文章编号:1008-1739( 2021)09-63-4
Application of an Optimal Strategy Method for Warehouse
AGV Path Planning
WANG Haixia
(School of Application Technology, Suzhou Universiy. Kunshan 215325, China)
Abstract: The path planning is a key technology in the path management system of Automatic Guided Vehicle System (AGVS),which is mainly used to plan the operation path of single or multiple Automatic Guided Vehicles (AGV)s in intelligent storage. A pathplanning strategy for heap optimization based on Dijkstra algorithm is studied and tested. Through a path planning case of multipleAGVs in a warehouse. it is verified that this method can achieve the optimal path planning strategy for single vehicle and multiplevehicles. shorten the operation time of the vehicle in the warehouse. and improve the use efficiency of AGVs.
Keywwds: AGVS path management system; Dijkstra algorithm; optimizing strategy
O引言
目前國内对AGV的应用需求日渐增多,因其柔性好、可靠性高、适用性强的特点,并且能实现生产搬运功能的集成和自动化,在各个行业中都得到广泛应用,其需求量正以井喷式的势头增长,如智能立体库、智能工厂、海港及码头等,随着自动化立体仓库和柔性制造系统的广泛应用,AGV作为智能物流系统连续化的重要组成部分,其精确性和高效性起着至关重要的作用[1]。
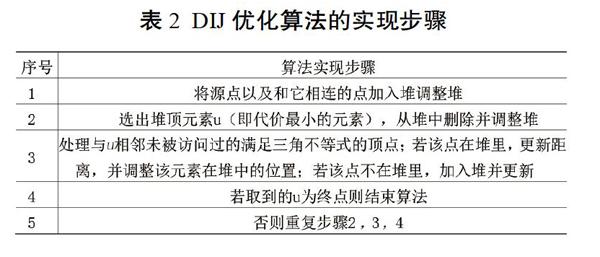
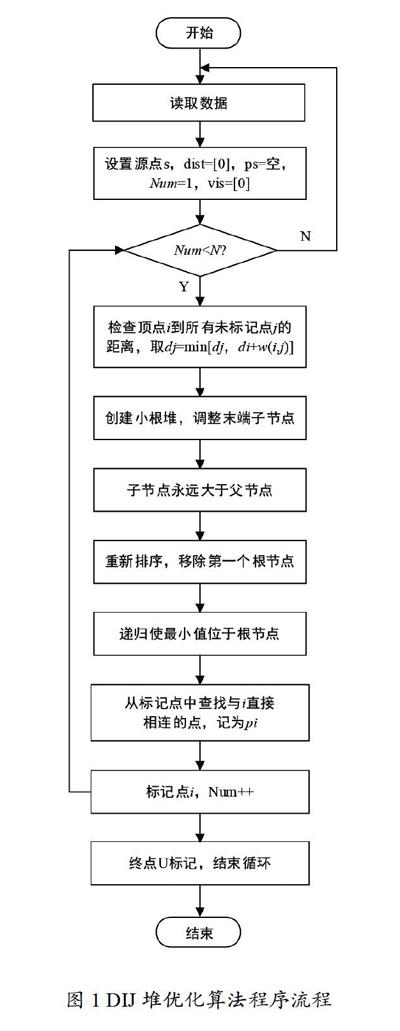
仓储AGV路径规划的最优策略方法,能够对AGV进行最优策略下的单车调度和多车调度,提高了AGV运行效率。目前这种调度方法成功用于仓储智能化物流系统,经现场证实,这种路径规划策略快速、准确、有效,比普通方法减少耗时15%以上。文中最优策略方法的实现采用了基于Dijkstra的堆优化算法,是最短路径优化算法之一,结合路径管理系统的starPlantOverview程序,能够实现AGV在智能仓储中的应用。
1仓储AGV路径管理系统的功能
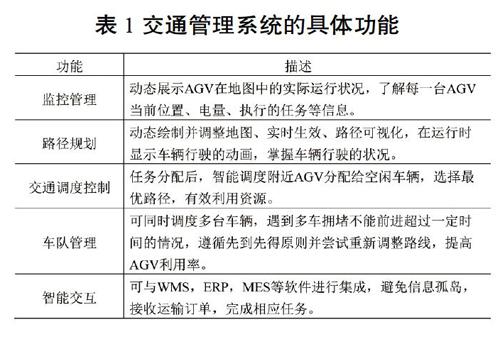
仓储AGV路径管理系统有以下几个功能:监控管理、路径规划、交通调度控制、车队管理和智能交互,功能描述如表1所示,主要目的是管理、监控和调度AGV执行搬运作业任务。……
