基于深度学习的实时车辆检测研究
2021-03-08黄生鹏范平清
黄生鹏 范平清


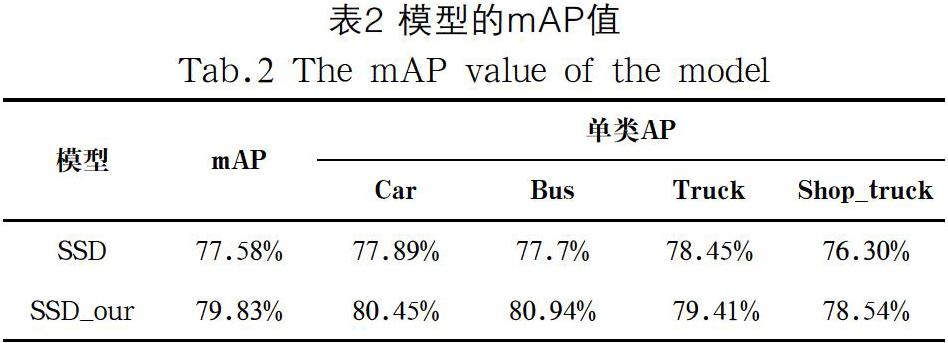
摘 要:针对城市交通复杂场景下车辆检测存在准确率低的问题,提出改进SSD(单发多箱探测器)目标检测算法。首先基于轻量化的PeleeNet(一种基于密集卷积网络的轻量化网络变体)网络结构改进SSD算法中VGG16(视觉几何群网络)特征提取网络,在保证提取丰富特征的前提下,有效地减少模型参数,提高模型的实时性;其次设计了多尺度特征融合模块和底层特征增强模块,提高特征的表达性能;最后根据数据集中目标的大小调整默认框的长宽比例,并在后三个特征层的每个单元上增加默认框。实验结果表明,改进后的目标检测算法的准确率mAP(平均精度)为79.83%,與原始SSD相比提高了2.25%,并验证了改进SSD算法的有效性。
关键词:实时性;SSD;默认框;特征提取
中图分类号:TP391 文献标识码:A
文章编号:2096-1472(2021)-01-13-04
Abstract: This paper proposes an improved SSD (Single Shot Multiple Box Detector) target detection algorithm to improve the vehicle detection accuracy in complex urban traffic scenarios. Firstly, VGG16 (Visual Geometry Group Network) feature extraction network algorithm in SSD is improved based on the lightweight PeleeNet (A lightweight network variant based on dense convolution network.) network structure. Under the premise of ensuring the extraction of rich features, it can effectively reduce model parameters and improve the real-time performance of the model. Secondly, a multi-scale feature fusion module and a low-level feature enhancement module are designed to improve the expression performance of features. Finally, length-width ratio of the default frame is adjusted according to the target size in data set, and the default frame is added to each cell of the last three feature layers. Experimental results show that the accuracy of mAP (mean Average Precision) of target detection algorithm is improved to 79.83%, which is 2.25% higher than the original SSD. So the improved SSD algorithm is verified to be effective.
Keywords: real-time; SSD; default frame; feature extraction
1 引言(Introduction)
高级辅助驾驶系统(Advanced Driver Assistance Systems, ADAS)是提高行车安全的重要技术手段之一,能否对行车环境中前方行驶车辆进行有效的实时检测是完成ADAS功能的首要前提[1]。
目前,视觉车辆检测技术主要分为两类:基于传统图像特征的目标检测算法和基于深度学习的目标检测算法。传统的目标检测算法主要采用人工设计的目标物特征,如HOG(Histogram of Oriented Gradient)[2]、Haar(Haar-like features)[3]等,将这些特征送入SVM(Support Vector Machines)[4]等分类器中进行目标分类检测。基于深度学习的目标检测算法主要有两个分支:以R-CNN(Region-based Convolutional Neural Networks)[5]、Fast R-CNN[6]、Faster-RCNN(Towards Real-Time object Detection with Region Proposal Networks)[7]、R-FCN(Object detection via region-based fully convolution networks)[8]算法为代表的基于候选框的两阶段目标检测算法;另一条路线是以YOLO(You Only Look Once)[9]、SSD[10]、Retina-Net(Focal Loss for Dense Object Detection)[11]为代表的单阶段目标检测算法。基于深度学习的单阶段目标检测算法是当前应用于车辆实时性检测的主流方法,尤其是SSD目标检测框架的应用场景广泛。……