基于模糊Elman网络算法的移动机器人路径规划分析
2020-04-22荣蓉
荣蓉
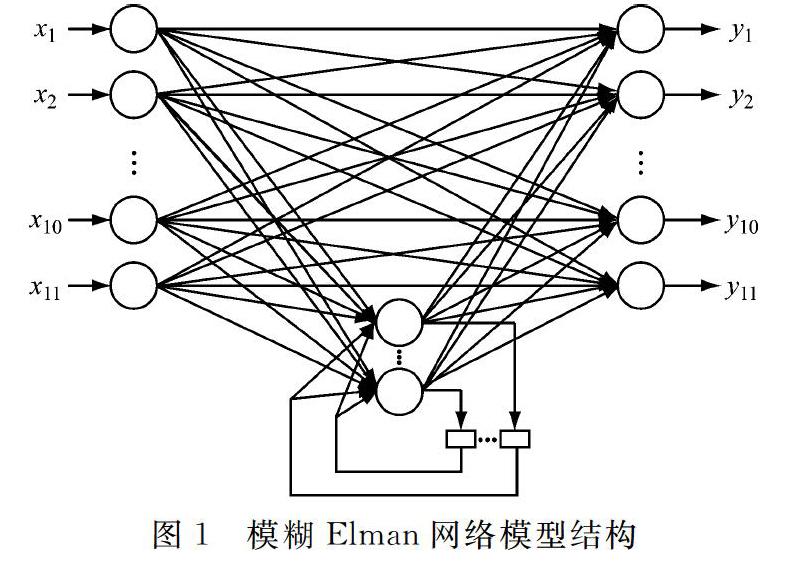
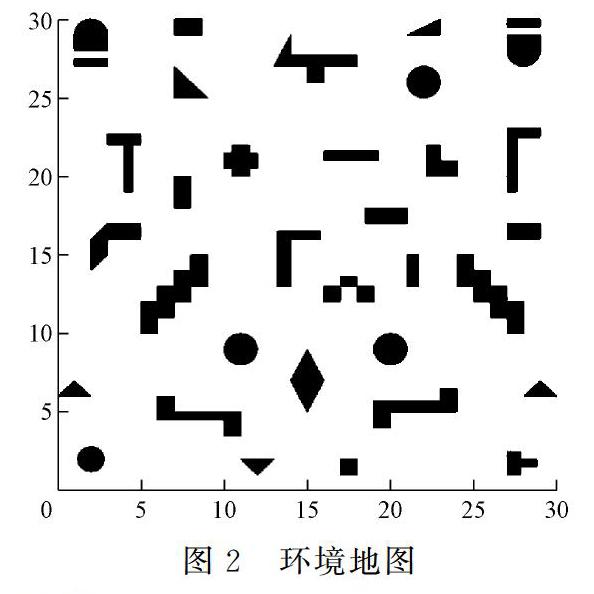
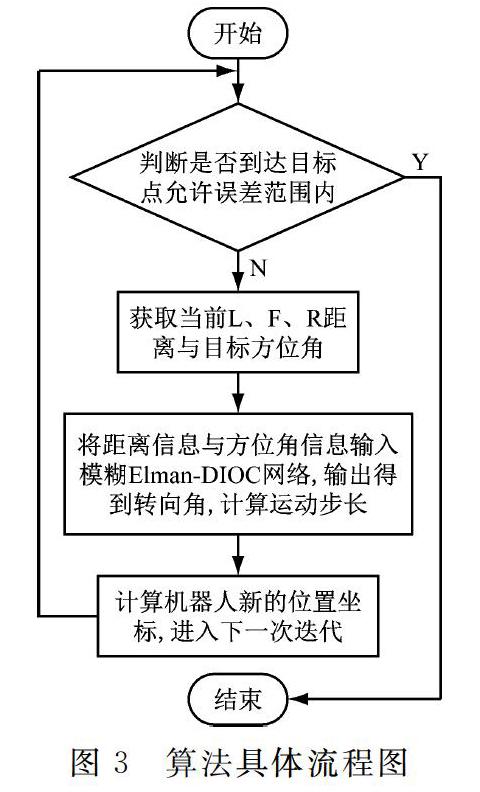
摘 要:为了调正移动机器人避障线路,建立了基于模糊Elman网络算法的移动机器人路径规划模型,并应用进行Matlab仿真分析。利用现有障碍物的距离信息来实现机器人步长的实施可控制与调节,防止移动机器人在做出准确避障行为之后因为没有设定合适的步长而导致撞上障碍物,以0.5作为机器人的最初运动步长。仿真结果表明,采用模糊Elman网络可以获得比其它两种方法更优的路径规划效果,同时对障碍物进行高效避让,由此实现最优的路径规划。采用模糊Elman网络来构建得到的路径规划算法能够满足规划任务的要求,同时还能够根据机器人处于不同工作空间中的情况进行灵活调整。
关键词:模糊Elman网络算法; 移动机器人; 路径规划; 避障
中图分类号: TM715
文献标志码: A
Abstract:In order to raise the obstacle avoidance line, a path planning model of mobile robot based on fuzzy Elman network algorithm was established, and Matlab simulation analysis was carried out. In this study, distance information of existing obstacles was used to realize controllable and adjustable robot step length, so as to prevent the mobile robot from colliding with obstacles due to not setting appropriate step length after making accurate obstacle avoidance behavior. 0.5 is taken as the initial movement step length of the robot. Simulation results show that the fuzzy Elman network can achieve better path planning effect than the other two methods, and at the same time, avoid obstacles efficiently, so as to achieve the optimal path planning. The path planning algorithm constructed by fuzzy Elman network can meet the requirements of planning tasks, and can be flexibly adjusted according to different working spaces of robots.
Key words:Fuzzy Elman network algorithm; Mobile robots; Path planning; Obstacle avoidance
0 引言
为了使移动机器人顺利完成运动路径控制,需要采用路径规划技术来保证机器人顺利规避运动阶段遇到的各类障碍物,并迅速找到最优替代路径[1-5]。为充分提高路径规划过程的灵活性并快速适应不同路径状况,选择模糊Elman网络理论作为分析架构,构建得到路径规划算法,同时具备Elman网络以及模糊控制的共同优点,表现出了优异的信息并行处理以及泛化分析性能,可以将其用于处理一些不确定信息,同时还可以把专家的经验也转变成以网络形式进行输入与输出的映射,上述映射关系可通过模糊Elman网络来精确表达,从而为移动机器人提供更优的路径规划方案[6-8]。……