基于 ZYNQ 的水下双目实时图像采集与处理系统设计
2024-07-08张崇丙李晓伟魏柠阳成月李锦
张崇丙 李晓伟 魏柠阳 成月 李锦

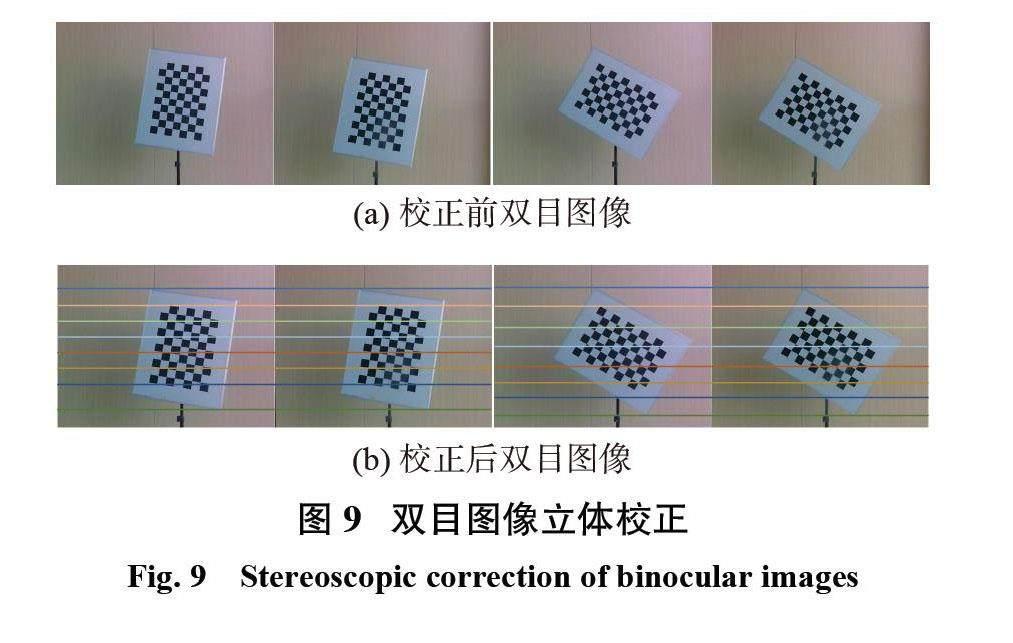
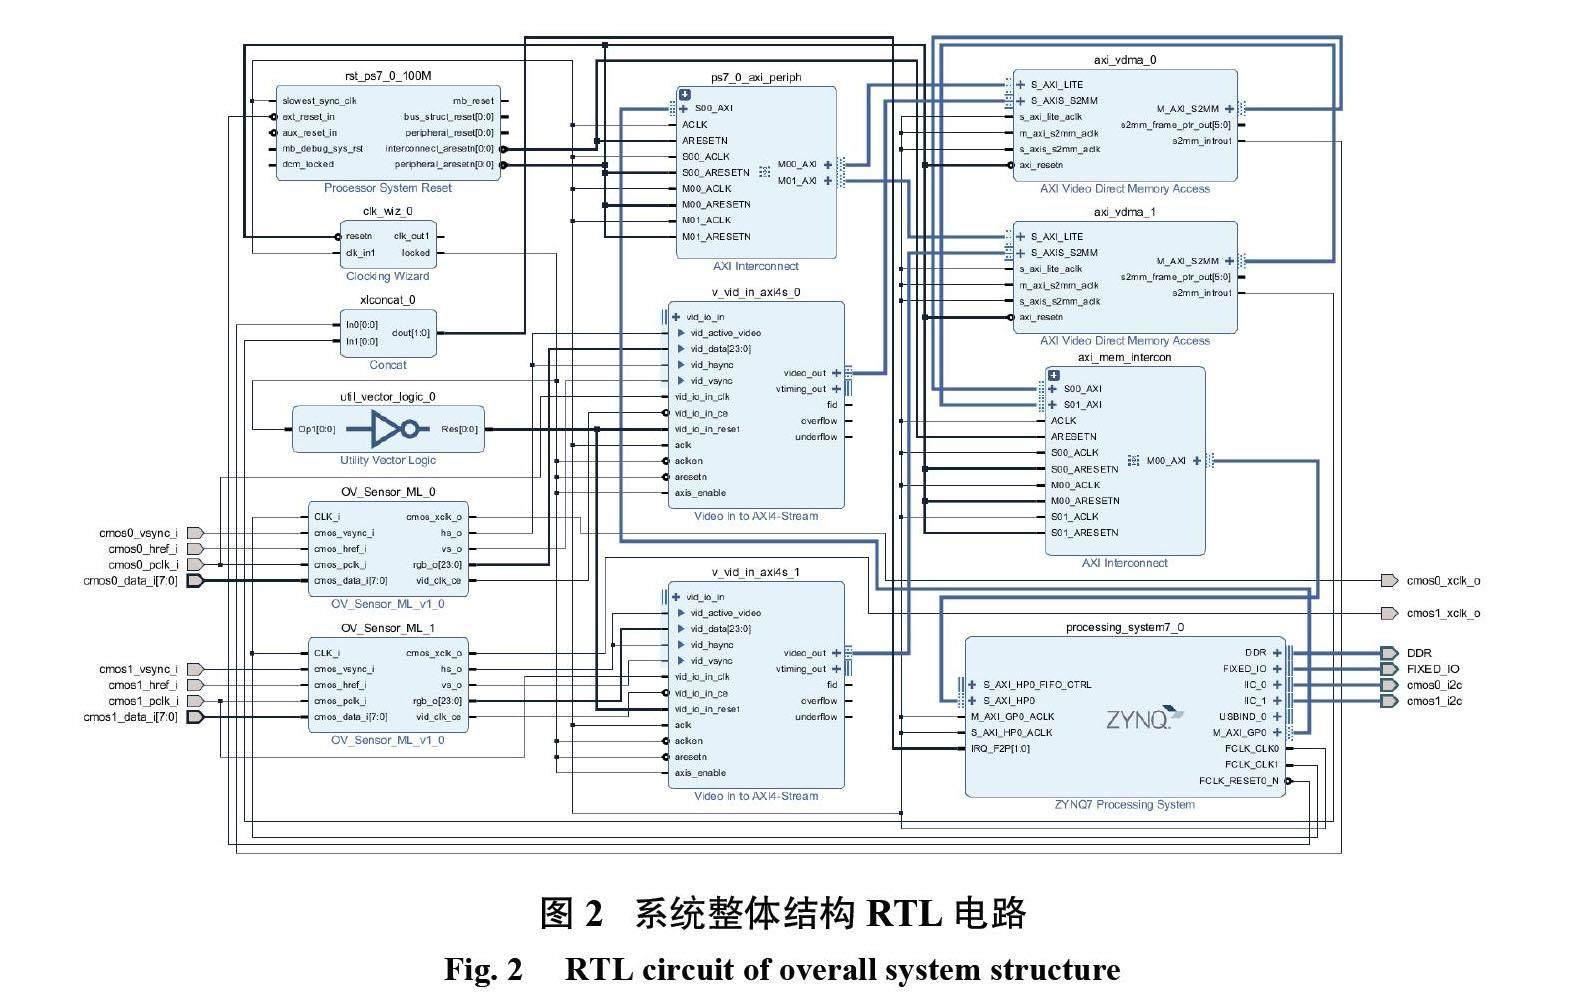
摘要:针对水下机器人近距离作业过程的水下目标探测需求,设计了一种基于 ZYNQ 的双目实时图像采集与处理系统,研制了水下双目相机工程样机。该系统由 FPGA 采集 OV5640图像传感器的视频数据,经 IP 核转换为 VDMA 支持的接口类型,通过 AXI4总线将数据传输到 PS 端的 DDR 中缓存,然后通过 PS 端的以太网将数据发送至上位机软件,数据经上位机软件解析后即可实现双目图像的实时显示与处理。实验结果表明:系统实现了在25 frame/s 帧率下1600 pixel×600 pixel 图像的实时采集和存储,双目图像标定后的重投影误差平均值为0.0542 pixel,通过立体校正实现了双目图像行对齐。这为进一步测试和实现水下目标测量定位及三维重建提供了可靠平台。
关键词:双目相机;ZYNQ ;图像处理;相机标定
中图分类号: TP 391.41 文献标志码: A
Design of a real-time underwater binocular image acquisition and processing system based on ZYNQ
ZHANG Chongbing,LI Xiaowei,WEINingyang,CHENG Yue,LI Jin
(China Ship Scientific Research Center, Wuxi 214082, China)
Abstract: To meet the requirements of underwater target detection during close range operation of underwater robots, a real-time binocular image acquisition and processing system based on ZYNQ-7000(ZYNQ) was designed and an underwater binocular camera prototype was developed. The system collects video data from OV5640 CMOS based on FPGA, converts it to an interface type supported by VDMA through IP core, and transmits the data to the DDR cache on the PS through AXI4 bus. The data are then sent to the PC software via Ethernet on the PS. After the analysis using the PC software, the binocular images can be real-time displayed and processed. The results show that the system has achieved real-time acquisition and storage of 1600 pixel ×600 pixel images at 25 frame/s, with an average reprojection error of 0.0542 pixel after binocular image calibration. Binocular image row alignment was achieved through stereo rectification. This provides a reliableplatform for further testing and achieving underwater target measurement, positioning, and 3D reconstruction.
Keywords: binocular camera; ZYNQ; image processing; camera calibration
引言
随着科学技术的发展,水下机器人在海洋科学研究、深海科考、海底勘探、水下作业等领域应用越来越广泛[1-3]。水下机器人典型的应用场景为海底样本采集、海底打捞、水下目标抓取等,这些水下作业过程都离不开对水下目标的定位和尺寸测量。当前水下目标测量与定位主要有两种方式[4-5]:水下声学探测技术和水下光学探测技术。水下声学探测技术以声呐为代表,其探测距离较远,但是受到空间分辨率的限制,只能获取目标物体的大致轮廓,适用于远距离大目标探测,在近距离探测时,精度较低。水下光学探测技术以主动式的结构光视觉探测系统和被动式的双目视觉系统为代表。……
