基于驾驶特性的ACC系统安全间距策略研究
2021-07-11施卫万广轩刘斌
施卫 万广轩 刘斌

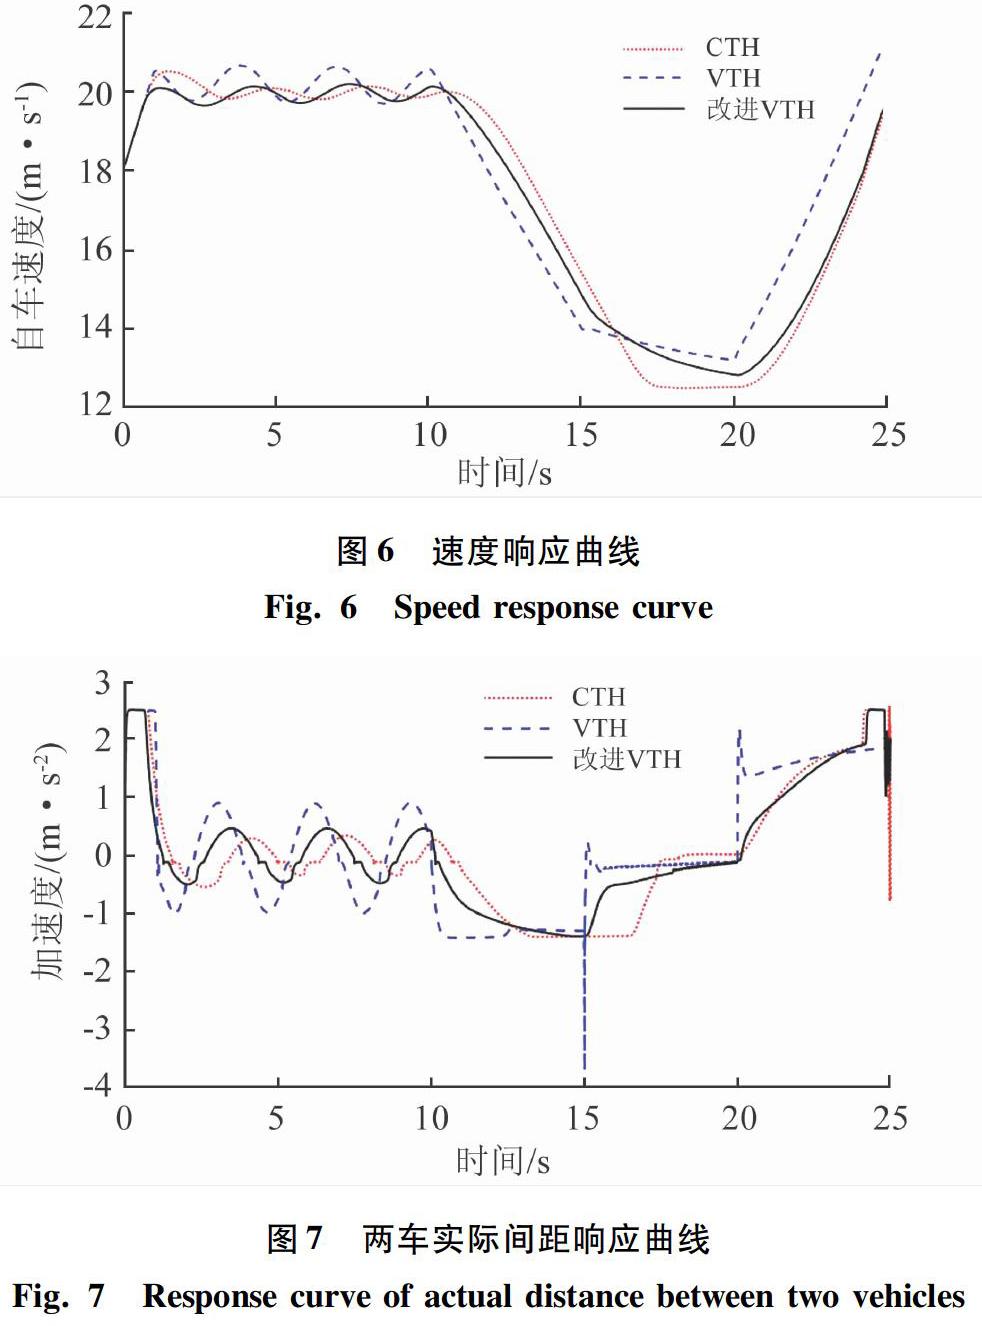
摘 要:为自适应巡航控制系统(ACC)提出一种基于驾驶特性的行车安全间距策略,在分析对比现行CTH和VTH算法各自的优劣后,考虑驾驶员动态跟车特性,以此为基础对VTH算法进行改进设计。在Matlab/Simulink和Carsim联合仿真平台下使用经典PID控制算法设计的ACC系统上层控制器对CTH、VTH及本文改进VTH策略进行稳态波动速度、急加/减速、恒定车速的复合工况仿真对比。结果表明,基于驾驶特性设计的改进VTH能够在传统VTH及CTH之间获取良好的平衡性能,既能对前车速度激变做出快速响应,也能以平滑且较低的加速度跟踪期望加速度,保证舒适性。
关键词: 自适应巡航控制系统;动态驾驶特性;可变车头时距策略;期望安全间距
文章编号: 2095-2163(2021)01-0156-05 中图分类号:U461.91 文献标志码:A
【Abstract】This paper proposes a safe driving distance strategy based on driving characteristics for the design of the ACC system. After analyzing and comparing the respective pros and cons of the current CTH and VTH algorithms, considering the driver's dynamic following characteristics, the design of VTH algorithm is improved. Under the Matlab/Simulink and Carsim co-simulation platform, the upper-level controller of the ACC system designed by the classic PID control algorithm is used to focus on CTH, VTH, and the improved VTH in this paper to simulate the compound operating conditions of steady-state fluctuating speed, rapid acceleration/deceleration, and constant vehicle speed. The results show that the improved VTH designed in this paper can obtain a good balance performance between the traditional VTH and CTH. It can not only respond quickly to the sudden changes in the speed of the preceding vehicle, but also track the expected acceleration with a smooth and low acceleration to ensure comfort.
【Key words】Adaptive Cruise Control system; dynamic driving characteristics; VTH; expected safe spacing
0 引 言
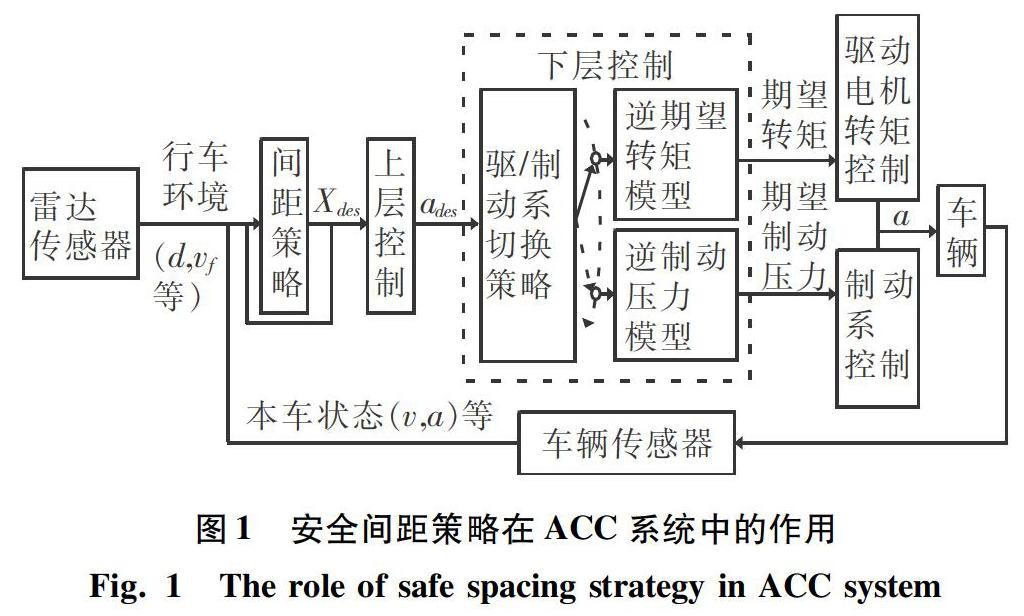
行車安全间距策略对自适应巡航控制系统(ACC)十分重要,任何ACC系统的开发都是从间距策略的选择和设计开始[1],如图1所示。间距策略指的是连续两辆车之间的理想稳态距离,其选择和设计决定了在整个跟车模式中ACC的表现。在跟车模式工作时,行车安全间距策略根据传感器获取数据信息实时计算行车期望安全间距,安全间距过小会导致ACC车辆与跟车目标处于不安全状态,使驾驶员无法处理突发状况,精神紧绷,而过大的安全距离则会导致相邻车道的频繁变道,所以合适的行车安全间距策略是非常重要的。
1 行车安全间距策略分析
安全间距通常定义为在前车不可预测的行为下避免追尾碰撞的最小间隔[2]。……