自适应抗差卡尔曼滤波对井下定位NLOS时延抑制方法的研究
2020-04-01李康乐邵小强潘红光郭德锋郑润洋卫晋阳
李康乐 邵小强 潘红光 郭德锋 郑润洋 卫晋阳
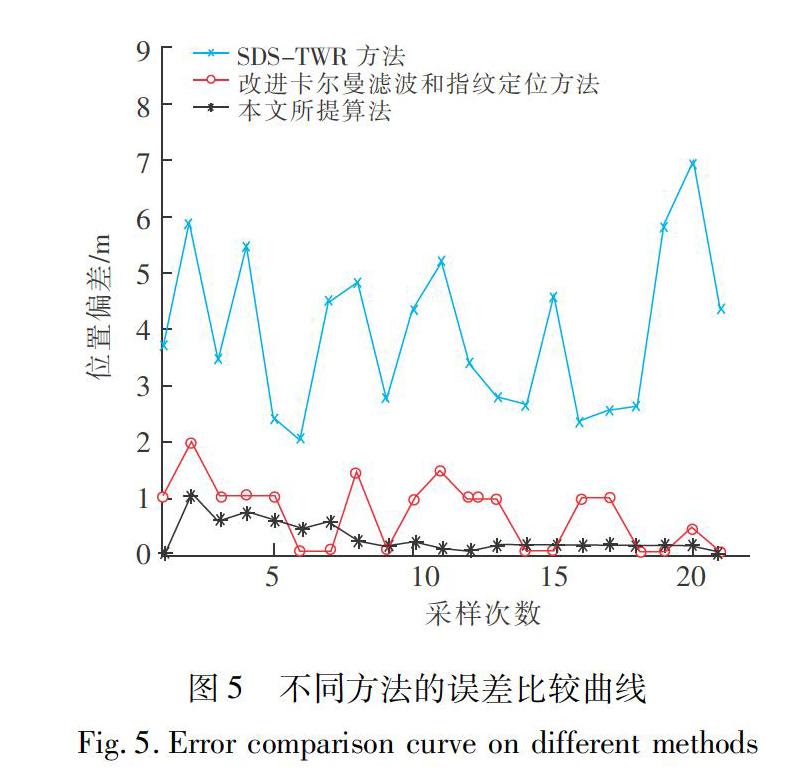
摘 要:針对矿井巷道NLOS(Non Line Of Sight)时延影响矿井TOA(Time Of Arrival)定位精度的问题,通过分析巷道NLOS时延形成方式,将巷道NLOS时延分为随机和固定两类,结合两类巷道NLSO时延的特性,提出了一种基于自适应抗差卡尔曼滤波的巷道NLOS时延抑制方法。对于巷道随机NLOS时延,通过在经典卡尔曼滤波算法的基础上引入了自适应抗差概念,使系统在线性滤波的基础上增加了对随机脉冲误差的抑制能力;对于巷道固定NLOS时延,通过在巷道NLOS误差模型的基础上,构建巷道中信号传播距离与传播环境间的函数模型,并结合几何定位算法完成系统对固有误差的有效抑制。实验结果显示,包含有巷道NLOS时延的原始定位数据,误差在2.1~8.1 m之间,平均误差为3.7 m;原始数据经自适应抗差卡尔曼滤波算法处理后,误差在1.9~3.6 m之间,平均误差为2.5 m,定位曲线与实际移动曲线基本保持平行;再经参数拟合和几何算法处理,误差在0~1.0 m之间波动,误差平均值为0.27 m,且所提方法较原始定位数据,平均定位误差减小了3.43 m.从而表明,所提方法对巷道NLOS时延具有较明显的抑制作用,能够提高TOA井下人员定位系统的精确度。
关键词:矿井定位;NLOS;自适应抗差卡尔曼滤波;参数拟合;TOA
中图分类号:TD 76
文献标志码:A
文章编号:1672-9315(2020)01-0173-08
DOI:10.13800/j.cnki.xakjdxxb.2020.0123开放科学(资源服务)标识码(OSID):
Downhole positioning NLOS delay suppression
method
based on adaptive robust Kalman filter
LI Kang-le,SHAO Xiao-qiang,PAN Hong-guang,GUO De-feng,ZHANG Run-yang,WEI Jin-yang
(College of Electric and Control Engineering,Xian University of Science and Technology,Xian 710054,China)
Abstract:To solve the problem that the positioning accuracy of time of arrival(TOA) positioning method is susceptible to delay of the non line of sight(NLOS),and based on the analysis of the formation mode of mine roadway,the NLOS delay of the roadway was divided into random NLOS delay and fixed NLOS delay.Taking the characteristics of two kinds of NLOS delays into consideration,a method of mine TOA positioning based on improved Kalman filter and parameter fitting is proposed.In order to eliminate the random NLOS delay error in roadway,the concept of adaptively robust was introduced to the basis of the classical Kalman filter algorithm.On the basis of linear filtering,the system can suppress random impulse error.Meanwhile,in order to suppress the fixed NLOS delay error,the roadway range finding error model was proposed,in which the functional relationship between signal propagation distance and propagation environment was established.Thus,the inherent error can be reduced by using the geometric positioning algorithm.The simulation results indicate that the original positioning data containing the NLOS delay of the roadway has an error between 2.1 and 8.1 m and an average error of 3.7 m.After the measurement data was processed by the Kalman filter based on the threshold of innovation,the positioning error is kept between 1.9 and 3.1 m and an average error of 2.5 m,and the positioning curve is basically parallel to the actual movement curve.After being processed by the parameter fitting and geometric algorithm,the positioning error is between 0 and 1.0 m,and the average error is 0.27 m.By comparison with the original positioning data,the average positioning error of the proposed method is reduced by 3.43 m.It can be found that the proposed method has a prominent inhibitory effect on the NLOS delay,and has a great effect on improving the accuracy of TOA downhole crew positioning system.
Key words:mine positioning;NLOS;adaptive robust Kalman filter;parameter fitting;TOA
0 引 言
中国煤矿90%以上是地下煤矿,且随着煤矿采区的不断扩大和作业巷井的不断加深,对井下作业人员和设备的监控管理日益困难,而现有煤矿井下人员定位系统的定位精度无法达到当前数字矿井建设的要求[1-3]。……