林区货车ABS滑模控制器优化设计
2019-06-07杨云杰朱洪前冯磊华
杨云杰 朱洪前 冯磊华

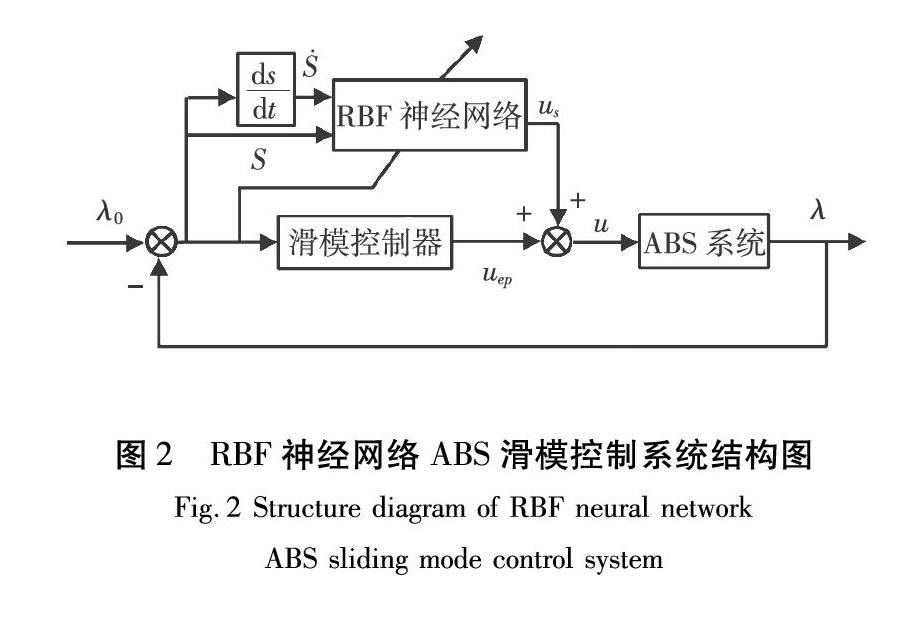
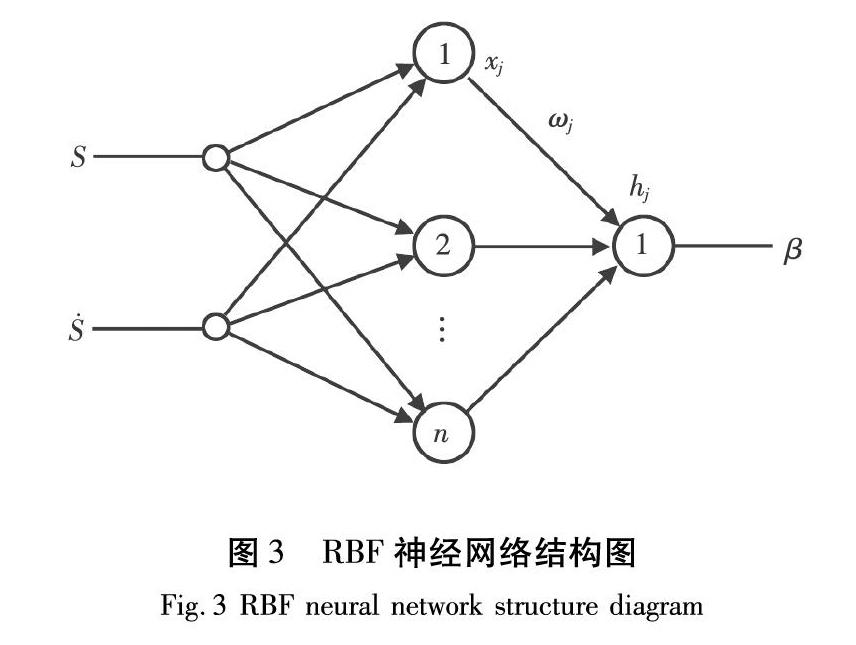
摘要:由于林区道路湿滑、路面状况复杂,采用传统控制方法的防抱制动系统存在响应速度慢、鲁棒性差等问题,制动效果不理想,为此本文提出RBF神经网络与滑模变结构相结合的控制方法,建立货车在林区制动情况的分析模型。实验结果显示:与常规滑模变结构控制相比,采用基于RBF滑模变结构控制的系统制动时间减少约0.185 s,制动距离缩短约1.88 m,到达最优滑移率和最大制动力矩的时间更快,系统更稳定。因此该方法不仅能够削弱常规滑模变结构控制所引起的抖振现象,而且能够提高ABS的响应速度和鲁棒性,能够很好地适应林区湿滑、复杂的路面状况,从而验证了所设计模型在实际应用中的可行性和有效性。
关键词:防抱制动系统;径向基函数;神经网络;滑模变结构控制;抖振
中图分类号:U463文献标识码:A文章编号:1006-8023(2019)02-0055-06
Optimization Design of ABS Sliding Mode Controller for Trucks in Forest Area
YANG Yunjie 1, ZHU Hongqian 1*, FENG Leihua 2
(1. College of Materials Science and Engineering, Central South University of Forestry and Technology, Changsha 410004; 2. College of Energy and Power Engineering, Changsha University of Science and Technology, Changsha 410004)
Abstract:Due to the slippery roads in the forest area and the complicated road conditions, the anti-lock braking system using the traditional control method has problems such as slow response speed, poor robustness, and poor braking effect. In this paper, the control method combining RBF neural network and sliding mode variable structure is proposed, and the analysis model of truck braking condition in forest area is established. The experimental results show that compared with the conventional sliding mode variable structure control, the system braking time based on RBF sliding mode variable structure control is reduced by 0.185 seconds, and the braking distance is shortened by 1.88 meters. The time to reach the optimal slip ratio and the maximum braking torque is faster and the system is more stable. Therefore, the method can not only weaken the chattering phenomenon caused by the conventional sliding mode variable structure control, but also improve the response speed and robustness of the ABS, and can well adapt to the wet and complex road conditions in the forest area. The feasibility and effectiveness of the designed model in practical applications are verified.
Keywords:Anti-lock braking system; radial basis function; neural network; sliding mode variable structure control; chattering
0引言
汽車防抱制动系统简称ABS系统,作用就是在汽车制动时,根据车轮转速自动管内压力的大小,让车轮处于边抱死边滚动的滑移状态,缩短制动距离,使方向保持良好稳定性的一种安全装置 [1]。ABS系统的作用决定了它必须具有较强的鲁棒性、实时性和抗干扰能力。目前,汽车防抱制动系统的控制方法有多种,其中主要的控制方式有:逻辑门限控制、PID控制、模糊控制、滑模控制和神经网络等 [2]。
当前国内外的ABS系统大多采用逻辑门限值控制方法 [3-4]。逻辑门限值控制算法虽然简单,但是需要大量实验获得,对本文所研究的林区复杂路面的适应性差,控制效果不是特别理想。……