电液伺服系统神经网络辨识及控制器设计
2017-11-06韩桂华王鹏飞张此军
韩桂华++王鹏飞++张此军
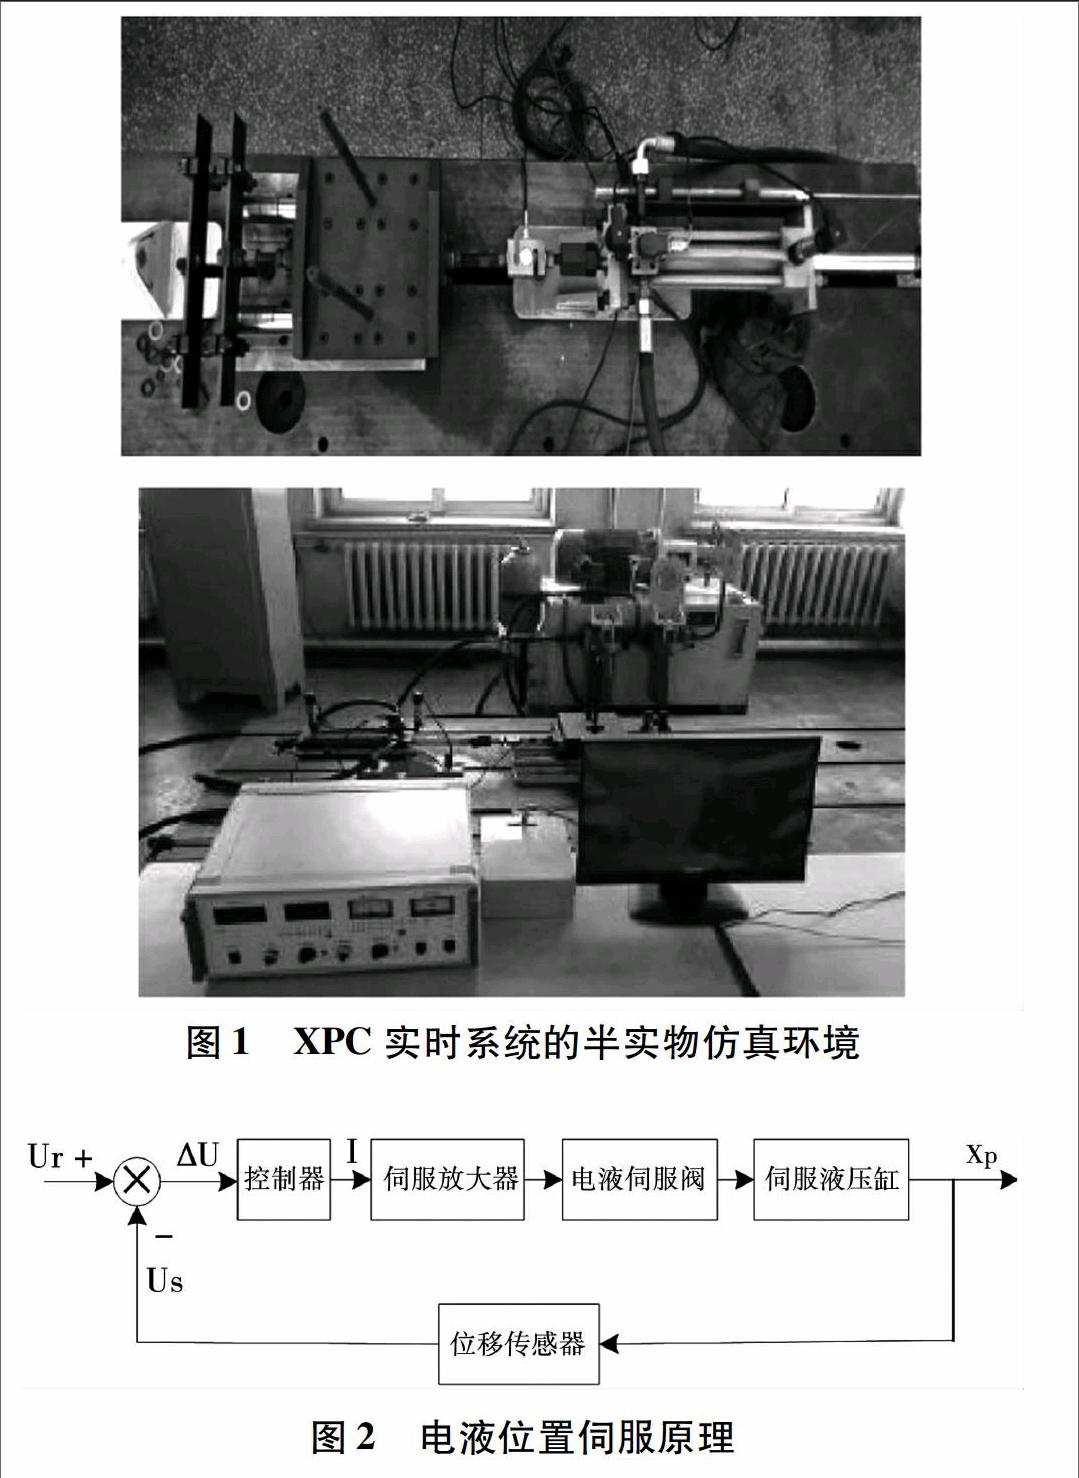
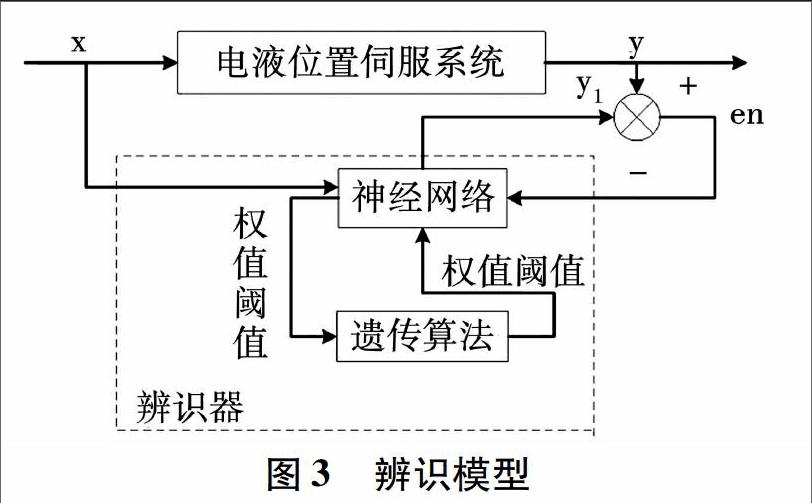
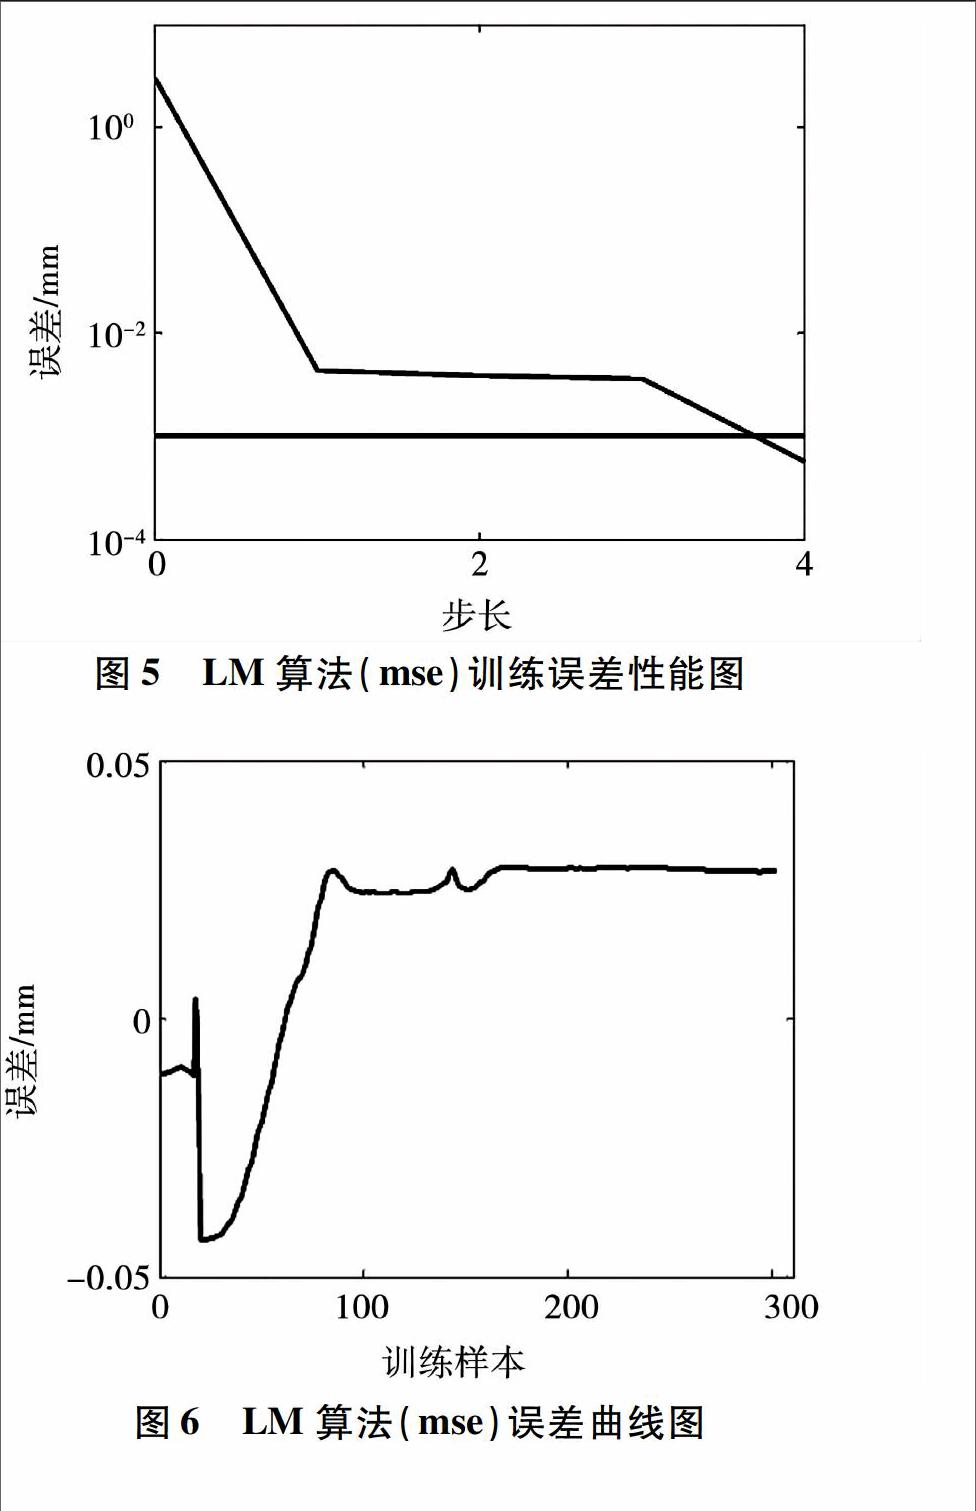
摘要:针对阀控缸电液位置伺服系统非线性建模问题,采用神经网络进行系统模型辨识。采用LM遗传算法对三层BP神经网络的权值和阈值进行修正,通过训练系统的输入/输出数据建立非线性系统辨识模型。基于此模型,设计模糊PI控制器,利用智能权函数在线自动调整和修改模糊控制器的规则。利用xPC技术建立阀控缸伺服实验台,以实验台阶跃输出信号作为改进BP神经网络辨识信号,以实验台正弦输出信号作为验证信号。实验表明:该神经网络辨识模型的可信性得以验证;通过对比智能权函数模糊PI控制器和模糊控制器的实验曲线,表明前者控制效果更好。
关键词:
改进BP神经网络;系统辨识;智能权函数;模糊控制;电液位置伺服系统;遗传算法
DOI:1015938/jjhust201705004
中图分类号: TP183,TP273
文献标志码: A
文章编号: 1007-2683(2017)05-0018-06
Neural Network Identification and Controller on Electrohydraulic Servo System
HAN Guihua,WANG Pengfei,ZHANG Cijun
(School of Mechanical and Power Engineering, Harbin University of Science and Technology , Harbin 150080, China)
Abstract:The neural networks system identification was used in nonlinear model on valvecontrolcylinder electrohydraulic position servo system The three layers BP neural network weights and threshold were optimized using LM genetic algorithm, the relationship of system input and output was analyzed and neural network identification model was presented A kind of fuzzy PI controller was designed based on the model, which can automatically adjust and modify the rules of fuzzy controller by using the intelligent weight function A real time electrohydraulic servo test bench was built with the xPC technique The test bench step output was used to identify in the improved BP neural network and the sinusoidal output was used to verify in experiment Experiment results show that the credibility is verified on neural network identification model; and that the control effect of the intelligent weight function fuzzy PI controller is better than the fuzzy controller
Keywords:improved BP neural network; system identification; intelligent weight function; fuzzy control; electrohydraulic position servo system; genetic algorithm
收稿日期: 2016-02-13
基金项目: 国家自然科学基金青年科学基金(51405113);国家国际科技合作专项资助合作项目(2012DFR70840)
作者简介:
韩桂华(1972—),女,博士,教授,Email:641544105@qqcom;
王鵬飞(1990—),男,硕士研究生;
张此军(1990—),男,硕士研究生
0引言
建立系统的数学模型是控制理论的基础,电液伺服系统因系统的死区特性、增益以及自激振荡等是一个模型参数和结构不确定的非线性系统[1-3],因此,在工程应用中获得一个与实际系统完全等价的数学模型,并以此为基础进行控制器的仿真设计是非常困难的。神经网络广泛应用于众多领域,但在非线性系统模型辨识中还存在收敛速度慢,学习时间长等问题。……