自行小车避障的设计与实现
2016-06-14彭振华梁凯甲曾丽
彭振华+梁凯甲+曾丽
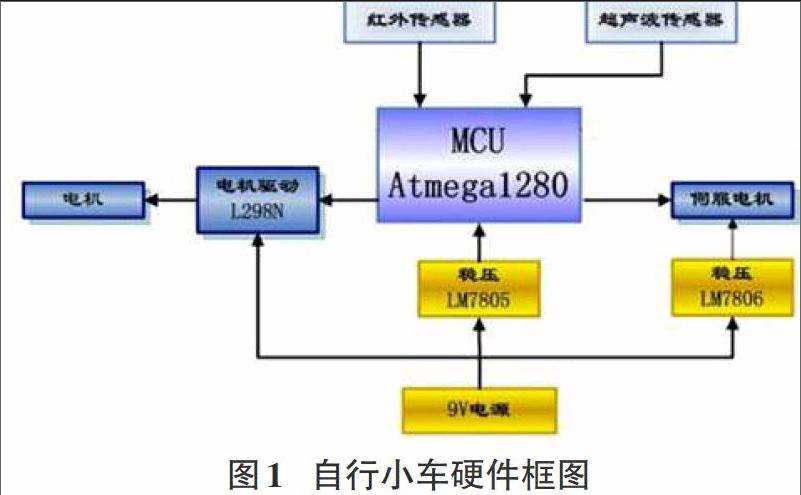
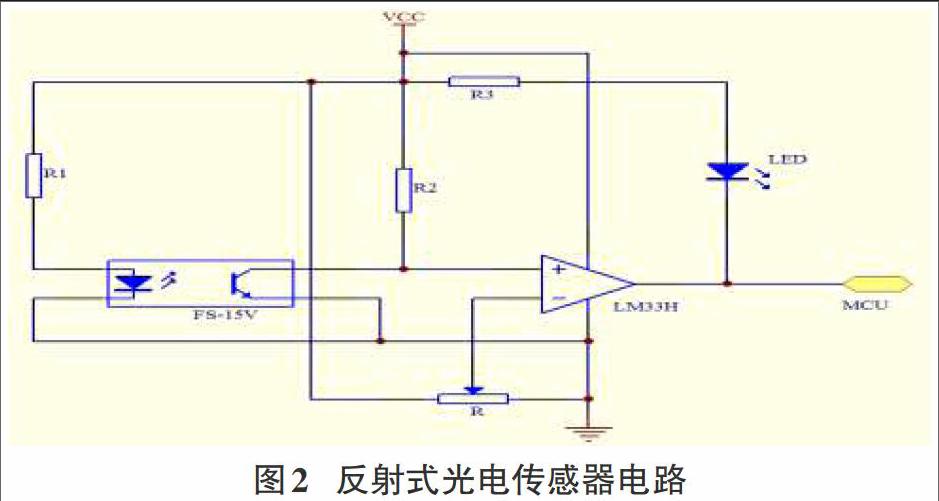
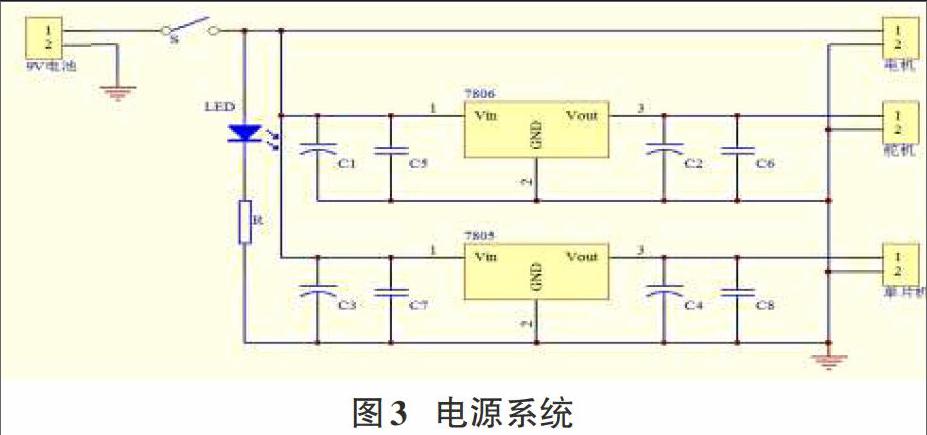
摘要:本文对自行小车的避障系统进行了研究,主要包括环境感知模块,中央处理模块和控制执行模块。控制算法引入人工势场法和最短切线路径法,将小车、障碍物、目标点简化为一点,在行驶过程中通过对障碍物距离及相对位置的探测,来实现局部路径规划,得出相应的避障路径,使小车顺利通过障碍物。通过对避障行为的研究,无论是软硬件还是算法,对自行小车的避障都有积极作用,具有一定的现实意义。
关键词:避障;路径规划;最短切线路径法;传感器
中图分类号:TP242 文献标识码:A 文章编号:1009-3044(2016)12-0257-04
Abstract: The self car obstacle avoidance system is studied,including environmental perception module, central processing module and control module. Control algorithm is introduced artificial potential field and the method of the shortest tangent path, the car, obstacles, simplify the target point is that in the process of moving through the obstacle distance and the relative position of the probe, to achieve local path planning, draw the appropriate obstacle avoidance path, so that the car passed the obstacle. Based on the research of the obstacle avoidance behavior, both hardware and software, or algorithms, self-avoidance car has a positive effect on, has certain practical significance.
Key words:obstacle avoidance;the tangent to the shortest path method;path planning; sensor
1引言
避障问题是目前自行小车运动的关键技术之一。但是在自行小车的发展过程中,因自行小车需要在不同的环境运行,常面临着这样的问题:当遇到障碍物时,如何根据环境和障碍物的情况选择最佳路径。
目前,计算机技术、自动控制技术[1-2]以及传感器技术[3]的发展给人们从重复简单或危险的劳动中解放出来提供了可能。因此,在工厂、仓库中常有一些用于物流的自行小车,生活中也有一些拥有自主导航能力的车辆。但是在自行小车的发展过程中,因自行小车需要在不同的环境运行,常面临着这样的问题:当遇到障碍物时,如何根据环境和障碍物的情况选择最佳路径。自行小车避障问题是目前自行小车运动的关键技术之一。对避障技术的研究有很大的现实意义。这项技术可以带来交通运输业的巨大改革,也为车辆的自主导航能力的实现和无人自动驾驶车辆的实现提供了重要技术[4-7]。……
