基于STM32的四轴飞行器遥控与智能防撞设计
2016-05-03李润宁缪月巫俊灵孙光阔陶心怡
李润宁 缪月 巫俊灵 孙光阔 陶心怡
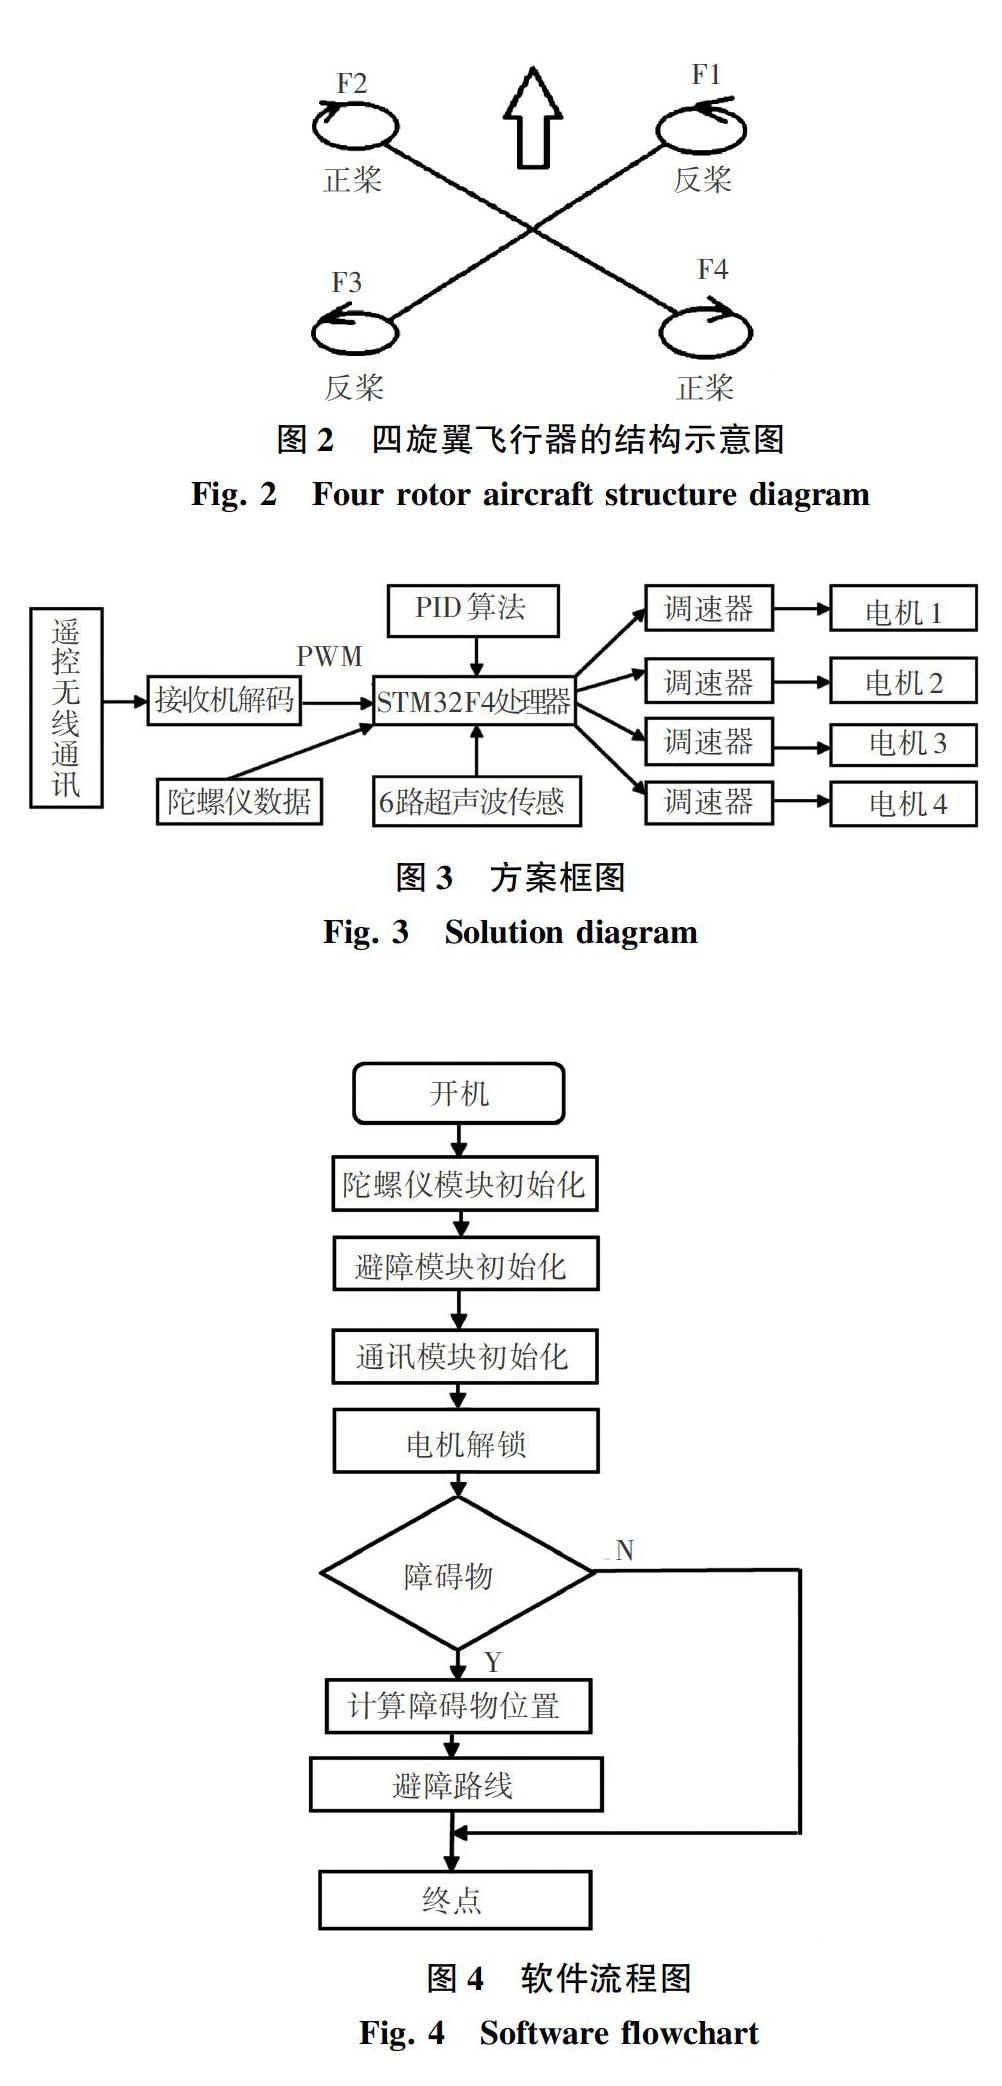
摘要:四轴飞行器具有结构简单、能耗低、体积小等优点,在多处领域被使用。在复杂环境中飞行,遇到障碍物时,通过人为操纵飞行器不断改变飞行状态避开障碍物难度较大,该设计利用6路超声波检测模块计算障碍物位置,实现自动避障。具有灵活性强、稳定性高等特点,大大降低了飞机坠机的风险。
关键词:四轴飞行器;智能避障;超声波避障
中图分类号:TP242.6 文献标识码:A文章编号:2095-2163(2016)02-
Design of remote control and intelligent collision avoidance of four axis aircraft based on STM32
LI Running,MIAO Yueqin,WU Junling,SUN Guangkuo,TAO Xinyi
(College of Electrical Engineering,Shanghai University of Engineering Science,Shanghai 201620,China)
Abstract:Four axis aircraft has the advantages of simple structure, low energy consumption, small volume, which is used in many fields. Flying in the complex environment, while encountering all the obstacles,it is difficult to changeaircraft flight status by manual manipulation aircraft. This paperproposesthe design of no.6 ultrasonic detection module, in which the position of obstacles is determined, and automatic obstacle avoidance is realized. The research has such advantages as strong flexibility and high stability, therefore greatly reduces the risk of the plane crash.
Key words:Quad rotor;intelligent obstacle avoidance;ultrasonic obstacle avoidance
0引言
四轴飞行器因其结构紧凑、飞行方式独特、切具垂直起降式特点,使其在军事和民用多个领域都已延伸拓展了广阔应用前景,同时非常适合在狭小空间内执行任务。而在复杂环境中飞行,并遇到障碍物时,试图通过人为操纵来不断改变飞行器飞行状态、从而避开障碍物的执行实施难度较大,更多情况下则会由于操作不当导致飞行器损毁,由此可知人为操作避障可靠性差、可行性低。基于此,本文提出了一种智能避障设计,旨在显著降低飞行器由于人为操作失误而坠毁的风险。
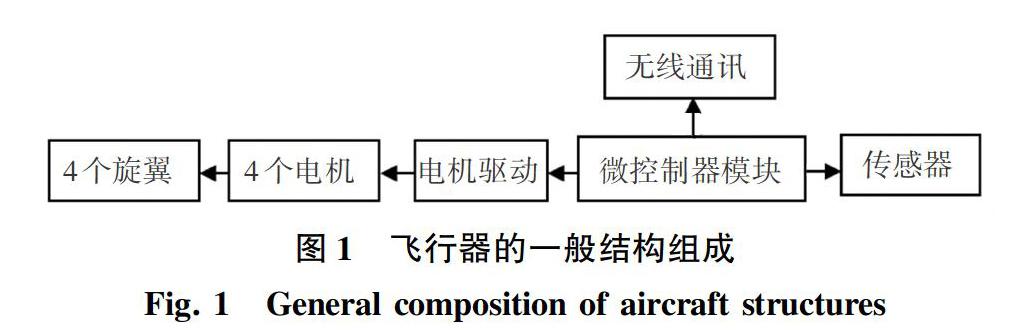
该设计利用姿态获取技术、PID控制算法、2.4G无线通讯技术和智能避障算法,实现对四轴飞行器的精准控制。系统的整体设计包括飞控部分、遥控部分和智能避障部分。其中,飞控部分采用STM32F407作为主控芯片,而且引入控制板和机架一体设计增强系统稳定性。遥控部分采用摇杆操作输入使操作体验可达现实极佳。控制板和遥控器之间采用2.4G无线通讯模块,保证数据稳定传输。……