基于图像处理的车辆防偏防追尾预警系统研究
2015-04-10赵检群许勇王善超
赵检群 许勇 王善超
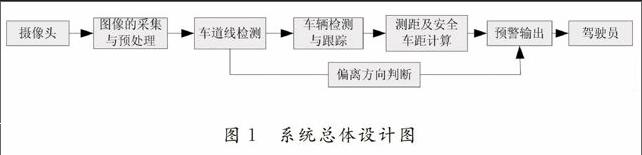
摘 要:针对交通事故的不断上升,设计一种基于图像处理的车辆防偏防追尾预警系统。首先利用改进的Hough变换检测出前方车道线并进行预警决策;然后在此车道区域内根据车底部阴影的梯度特征确定前方可能存在的车辆区域,通过卡尔曼滤波器跟踪检测到的目标,并利用归一化转动惯量做车辆验证;最后根据世界坐标系和图像坐标系之间的几何映射关系测定与前车的距离,进而与计算得出的安全距离对比从而实现报警功能。实验结果表明,该系统能够有效的识别出车道线和车辆,并能很好的判断车道线偏离情况和测量车间距,从而实现预警输出。
关键词:车道检测;Hough变换;车辆识别;卡尔曼滤波;单目测距;预警系统
中图分类号:TN911.73 文献标识码:A
Abstract:This paper designed a lane departure and rearend collision warning system based on image processing. The designed system firstly detects the lane by using the improved Hough transform method and then detects the vehicle ahead according to the gradient feature of shadow in this region of the lane. Kalman filters were used to track the target vehicle,which will be assisted by normalizedmutualinformation feature. Lastly the safe distance was calculated by image mapping in coordination system to world coordination system to realize alarm function. The experimental results show that the system can effectively detect lane lines and vehicles. The system can also detect the vehicle deviation and measure the distance between vehicles correctly, and give the early warning if necessay.
Key words:lane detection; Hough transform; vehicle identification;kalman filter; monocular measurement of distance; early warning system
1 引 言
随着汽车保有量的迅速增加,使汽车安全成为了现代汽车学上最重要的议题,各大汽车厂商也将产品的安全性能作为差异化竞争的重点之一[1]。如今传统的制动系统基本上已经走到了物理极限,主动安全系统将逐渐开始崭露头角。研究证明,若在公路交通事故发生前1.5s给驾驶员发出预警,则可避免90%的碰撞事故[2]。而车辆防碰撞预警系统是实现这一功能的重要手段,它能在事故发生前及时提醒驾驶员道路危险状况,为驾驶员提供更多的反应时间,使驾驶更为安全[3]。
目前国内外关于汽车智能防撞预警系统的研究,主要集中在防止车道偏离和保持安全车距这两个方面。……