可感知通信质量的中继通信机器人
2023-06-21陈永波张家强肖宇峰张佳雯
陈永波 张家强 肖宇峰 张佳雯
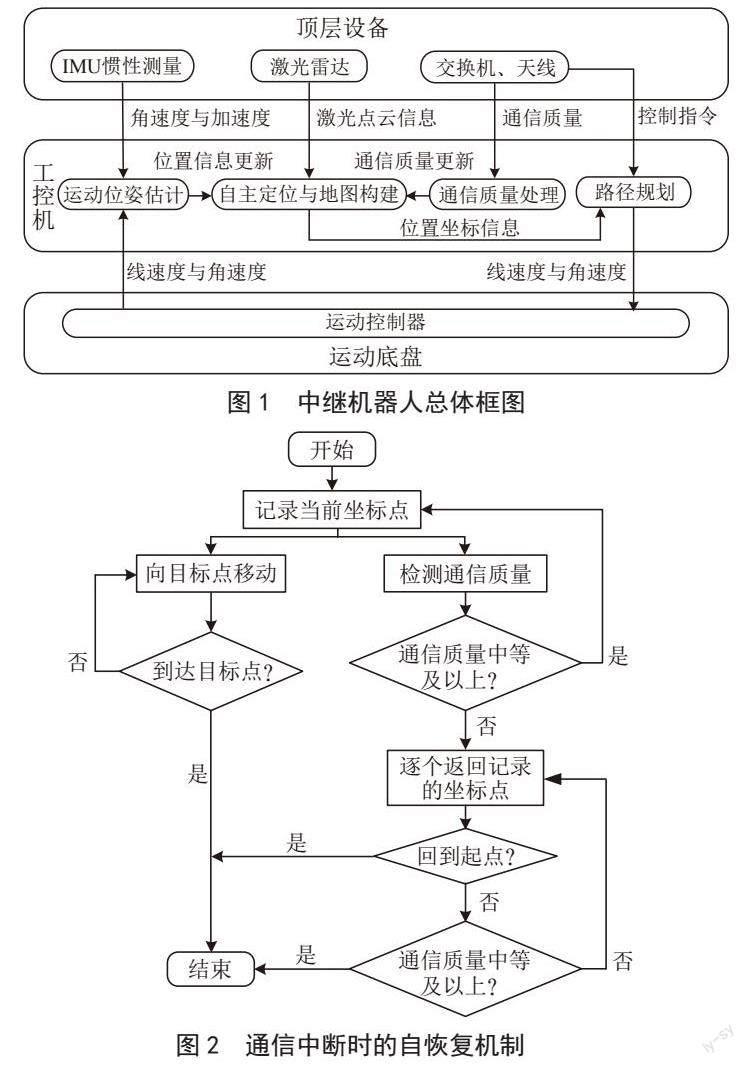
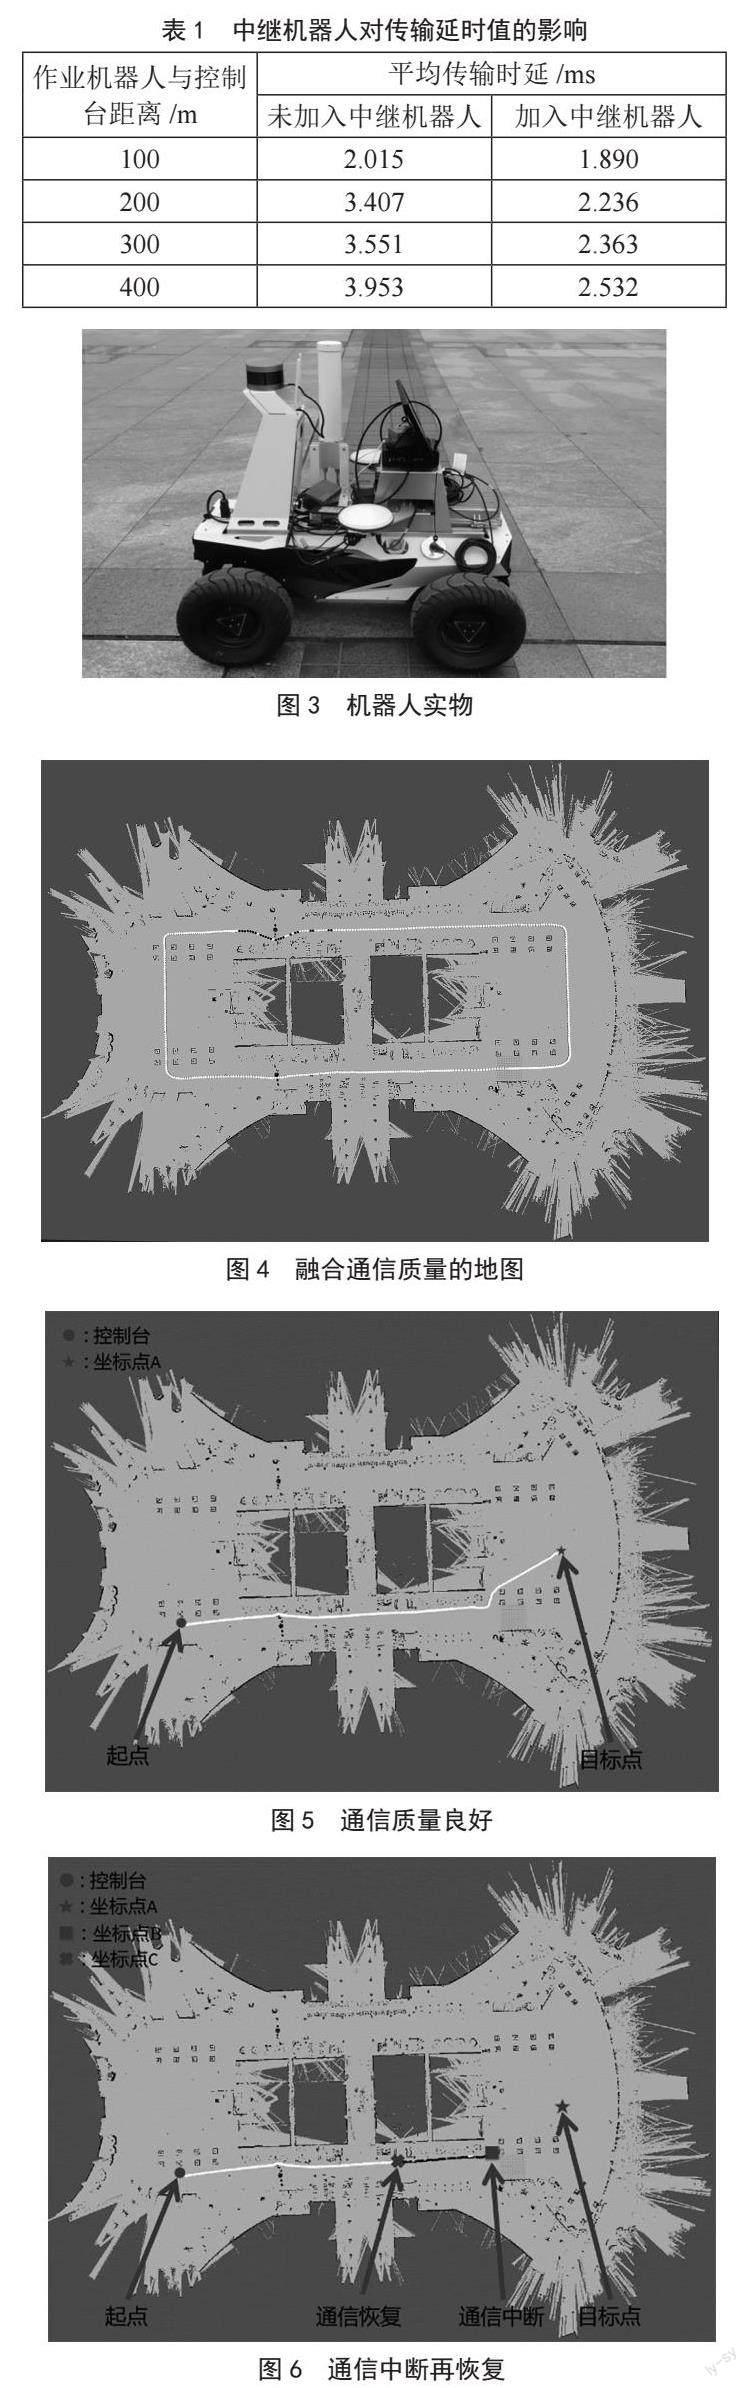
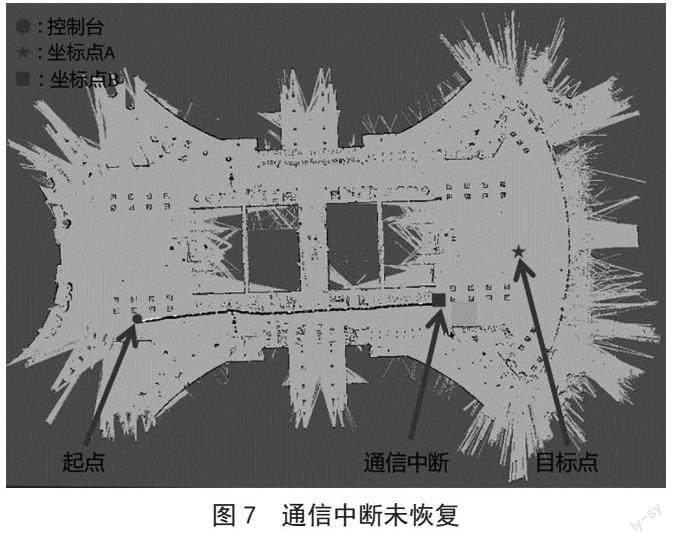
摘 要:针对复杂环境下移动机器人可靠作业需求,结合机器人自主导航、网络测量、通信组网等技术,设计可感知作业环境通信质量的中继通信机器人,为机器人调度、任务规划提供依据。主要内容包括:设计移动中继机器人,增强作业机器人与控制台之间通信质量;设计通信质量感知的地图构建方法,实现机器人作业环境通信质量的可视化;设计通信中断自恢复机制,实现通信中断情况下机器人的自主返回与通信连接恢复。
关键词:移动中继;自主导航;通信质量感知;通信中断自恢复
中图分类号:TP242;TN92 文献标识码:A 文章编号:2096-4706(2023)09-0192-04
Abstract: Aiming at the demand for reliable operation of mobile robots in complex environments, this paper combines technologies such as autonomous robot navigation, network measurement and communication networking to design relay communication robots that can perceive the communication quality of the operating environment and provide a basis for robot scheduling and mission planning. The main contents include designing a mobile relay robot to enhance the communication quality between the operating robot and the console, designing a map construction method for communication quality perception to realize the visualization of the communication quality of the robot's operating environment, designing a self-recovery mechanism for communication interruption to realize the robot's autonomous return and communication connection recovery in case of communication interruption.
Keywords: mobile relay; autonomous navigation; communication quality perception; communication failure self-recovery
0 引 言
近年來,机器人的应用领域不断扩展,人们希望通过机器人来处理复杂烦琐的任务。但对于许多复杂任务,单个机器人无法独立完成,需要多个具备不同功能的机器人协调合作才可以完成任务。由于多机器人系统包括很多不同功能的机器人,整套机器人系统需要不间断地进行数据交换来确保系统的正常工作,一旦出现通信中断,整套机器人系统都将受到影响,所以保证多机器人系统的通信质量成为重中之重。
多机器人通信是建立在无线通信的基础上,国内的研究已经取得了一定的积累。浙江大学工业控制实验室提出了一种多覆盖算法,在满足不同覆盖质量的基础上考虑了多目标覆盖和区域覆盖,不过该方法只考虑理想通信环境下的解决方案;沈阳自动化研究所针对无线网络节点控制问题,研究了网络节点的运动控制,但对无线网络节点的分布研究较少;……
