变刚度柔性机器人关节的设计与解耦控制方法
2019-08-05张明房立金孙凤孙兴伟
张明 房立金 孙凤 孙兴伟
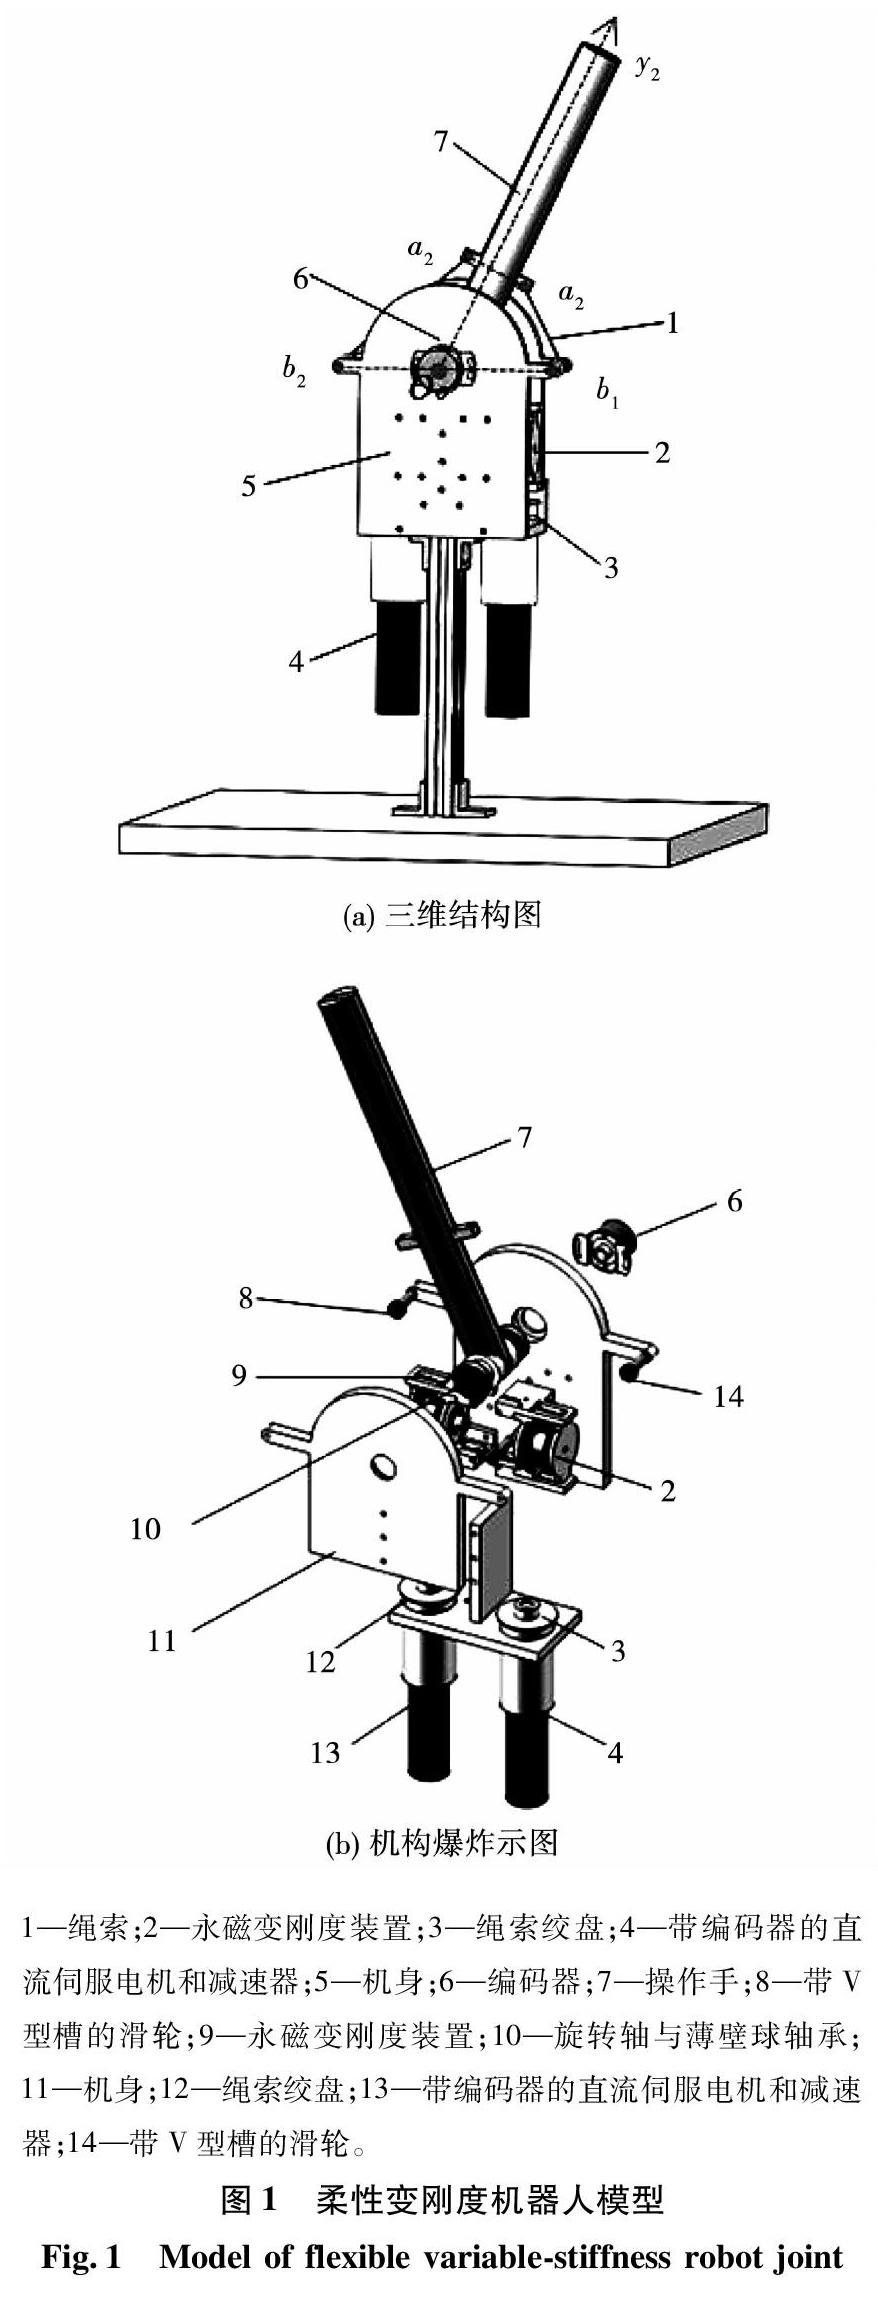
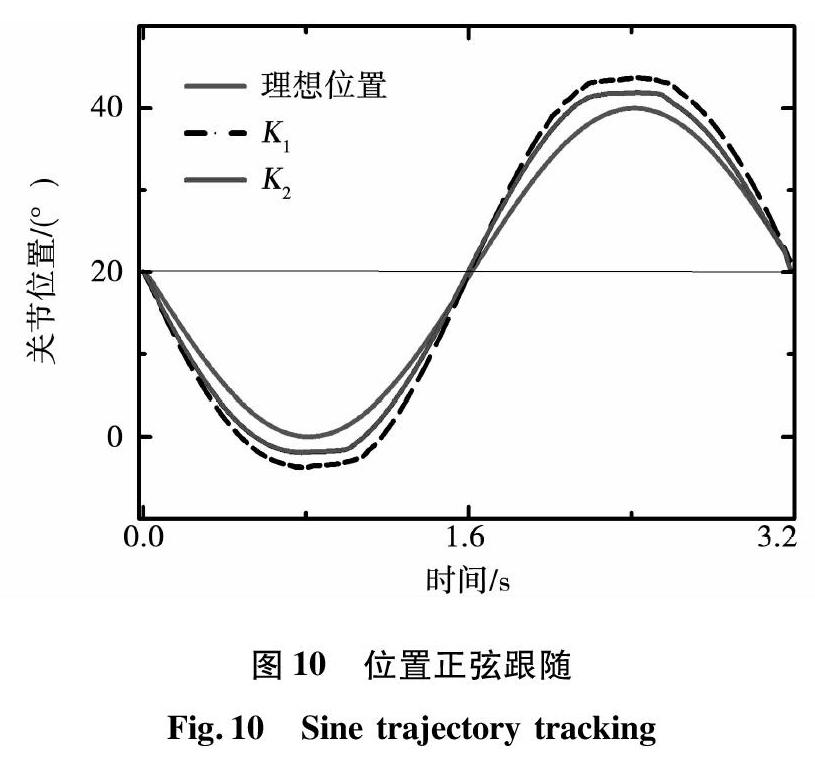
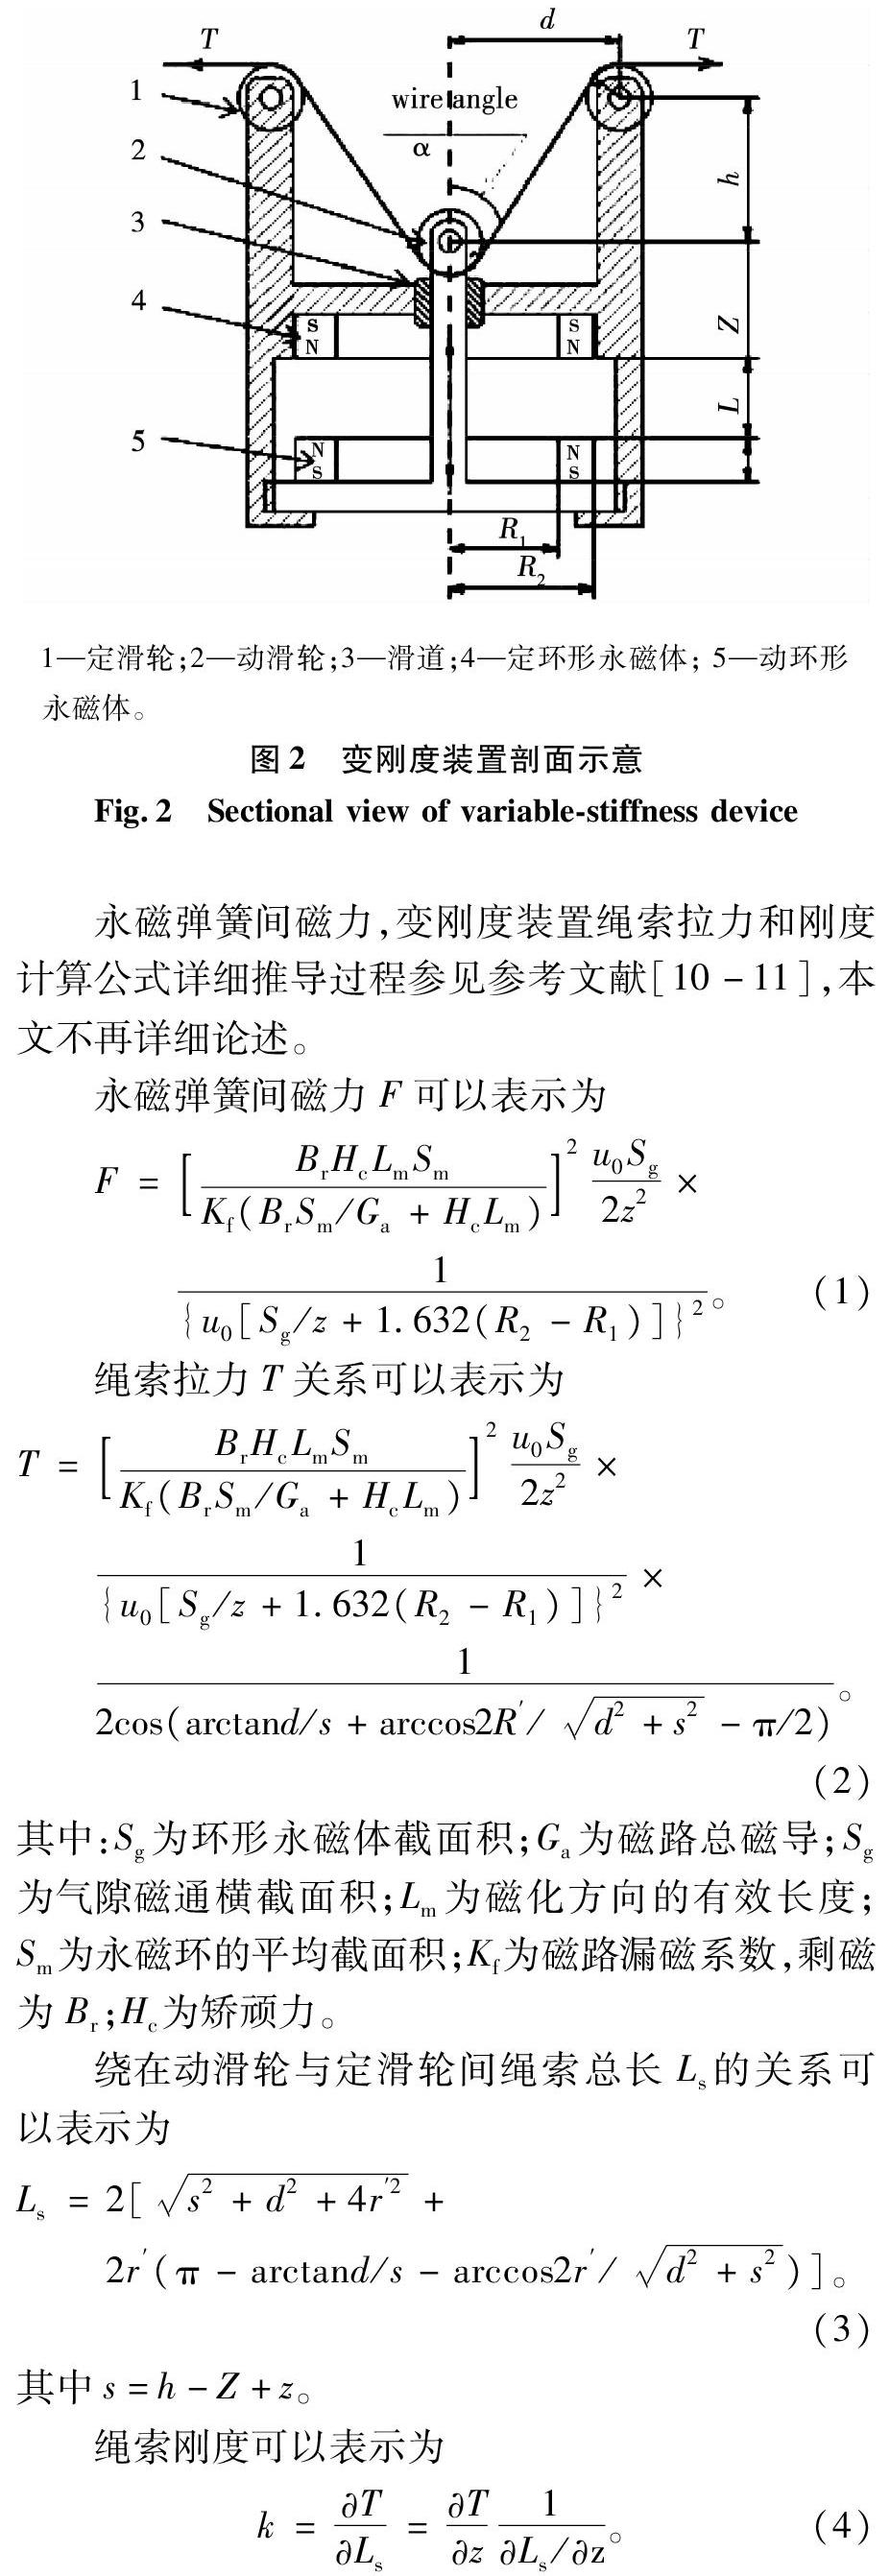
摘 要:设计一种采用永磁变刚度装置的绳索驱动式柔性机器人关节,在不增加驱动力的情况下,增加关节刚度调整范围。详细阐述关节的机械结构和变刚度原理。利用雅可比矩阵和模型间静力学关系,得到关节刚度,位置和绳索伸长量的对应关系,实现了刚度与位置解耦。建立变刚度关节的动力学模型,以轨迹控制为目标,设计解耦控制器,搭建实验系统,验证本方案的可行性。采用永磁弹簧,绳索驱动的柔性关节可以有效的减小关节的质量,惯性和体积,同时具有较大的刚度调整范围以及较短的调整时间,较快的响应速度和较小超调量。此柔性关节的构型和控制方式也适用于多自由度柔性并联机器人关节的构建。
关键词:变刚度;磁弹簧;绳索驱动;解耦控制器;柔性关节
中图分类号:TP 24
文献标志码:A
文章编号:1007-449X(2019)07-0120-09
Abstract:The wiredriven flexible robot joint using permanent magnetic variablestiffness mechanism was designed, which increases the variablestiffness range, without increasing the driving tension. The principle and structure of the variablestiffness flexible robot joint were explained. The correspondence between joint stiffness, joint position and wire length were obtained by using the Jacobi matrix and the mechanics relationship between models, which realizes the decoupling of stiffness and position. The dynamic model of the variablestiffness joint was established, a decoupling controller was designed, based on the trajectory control,and the experimental system was set up to verify the feasibility of the scheme. Using permanent magnet spring and wiredriven, the flexible joint can effectively reduce the weight, inertia and volume of the joint,and at the same time, it has a greater variablestiffness range, a shorter stiffness adjustment time, a faster response and a smaller overshoot. This configuration and control method are also suitable for multidegree parallel flexible joints.
Keywords:variable stiffness; magnetic spring; wiredriving; decoupling controller; flexible joint
0 引 言
柔性變刚度机器人关节是不同于传统刚性机器人关节的一类刚度可调的柔性机器人关节,由于自身刚度可调,可以很大程度的提高人机安全性和环境适应性,已经成为未来机器人发展的重要方向[1-9]。国内外学者在柔性变刚度机器人关节方面已开展了大量的研究和探索,提出了很多的方案和设计。其中主要有:意大利技术研究所(IIT)基于一种弹簧组合设计了一种紧凑的柔性驱动单元AWAS-Ⅰ及改进版AWAS-Ⅱ[3-4],工作原理是通过改变弹簧在杠杆臂上的位置改变刚度,通过控制杠杆臂的转角实现操……
